Specifications
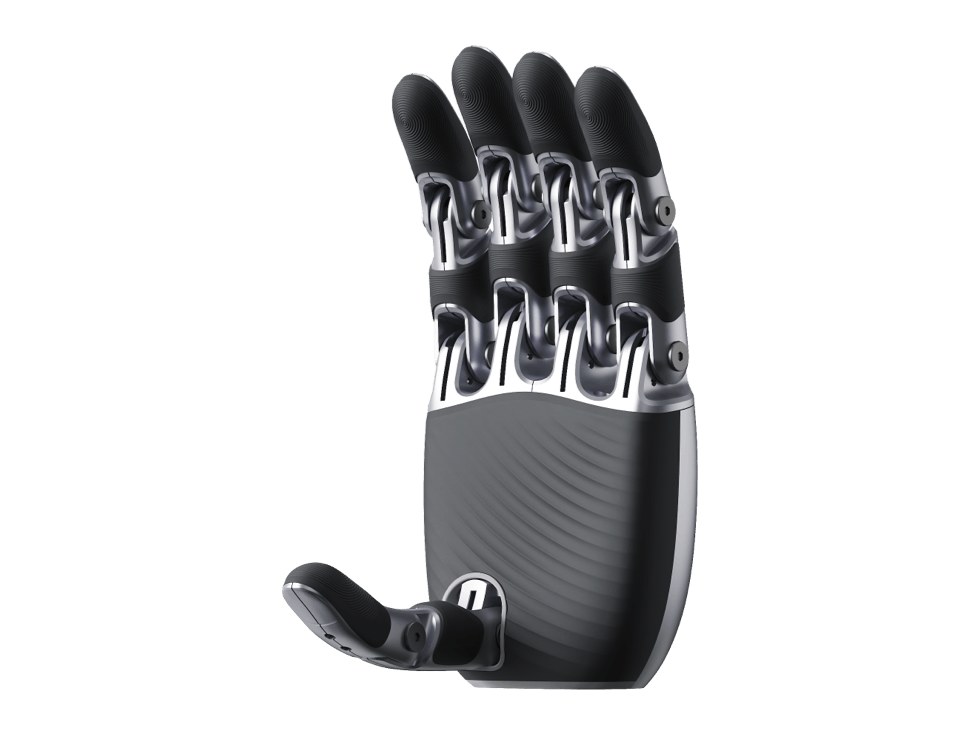
| DOF | 2 |
| Joints | 10 (four fingers 8, thumb 2) |
| Drive | Tendon-driven |
| Dimensions | approx. 151 × 67 × 70 mm |
| Weight | approx. 365 g |
| Operating voltage | 24 to 58 V |
| Fingertip force | 10 N |
| Tactile sensing | No |
| Development | Secondary development supported, robot development interfaces |
| Fits | AS2, R1, R1-A, R1 Arm, G1, G1+ and D2 |