H2 on a Lifting Column
UNIT://H2-D CONFIGS: 26 LIVE ZAR PRICING

H2-D .

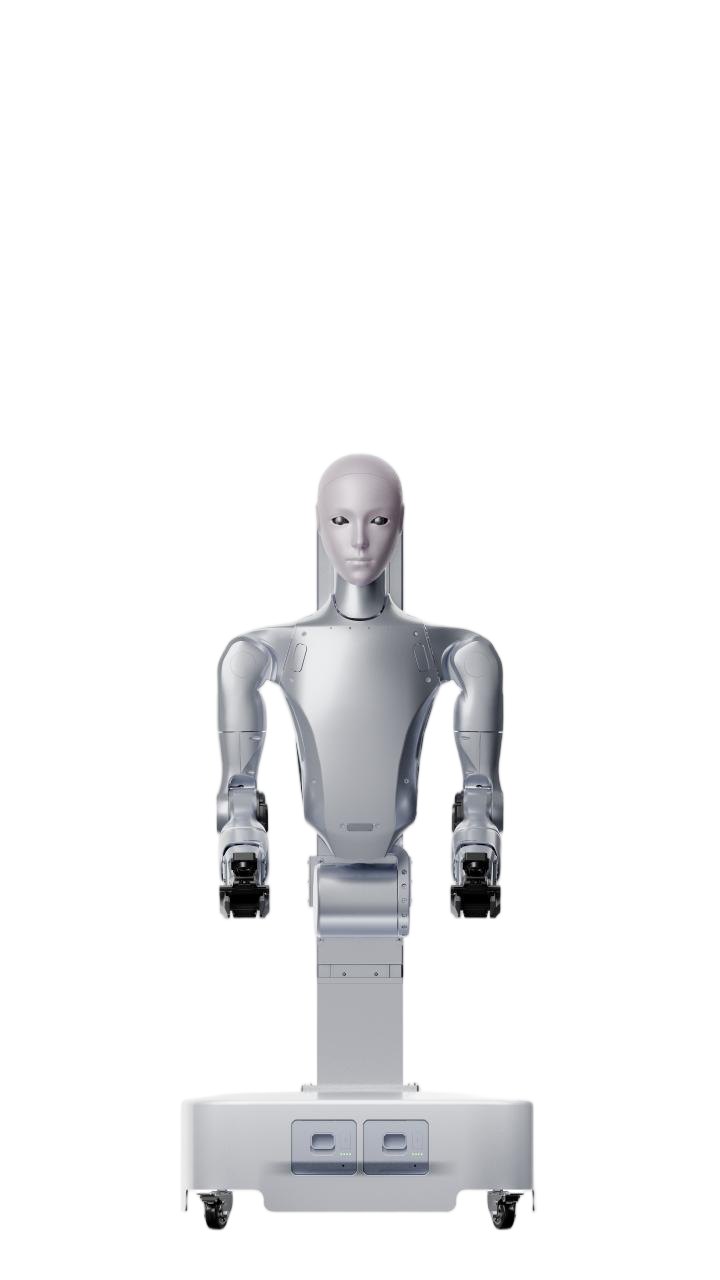
The H2 upper body on a lifting column: a manual-move chassis on 24/7 external power, or a mobile LiDAR chassis with a swappable 1.44 kWh battery.

from R 574,000EX VAT 26 configurations Warranty 12 months

Research-grade machinery for trained adult operators, not a toy. Read the Product Safety Notice before you order.
H2-D: Key figures FACTORY DATA
Dimensions 1700 x 560 x 605 mm at max. column height
Weight approx. 148 kg with battery
Total DOF 21 (7 per arm, 1 waist, 2 head, 2 column, 1 per gripper)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector, approx. 0.62 m with gripper
Lifting column 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base
An H2 Upper Body on a Lifting Column
It does not walk. For legs, choose the H2 or H2-X.

An H2 Upper Body on a Lifting Column

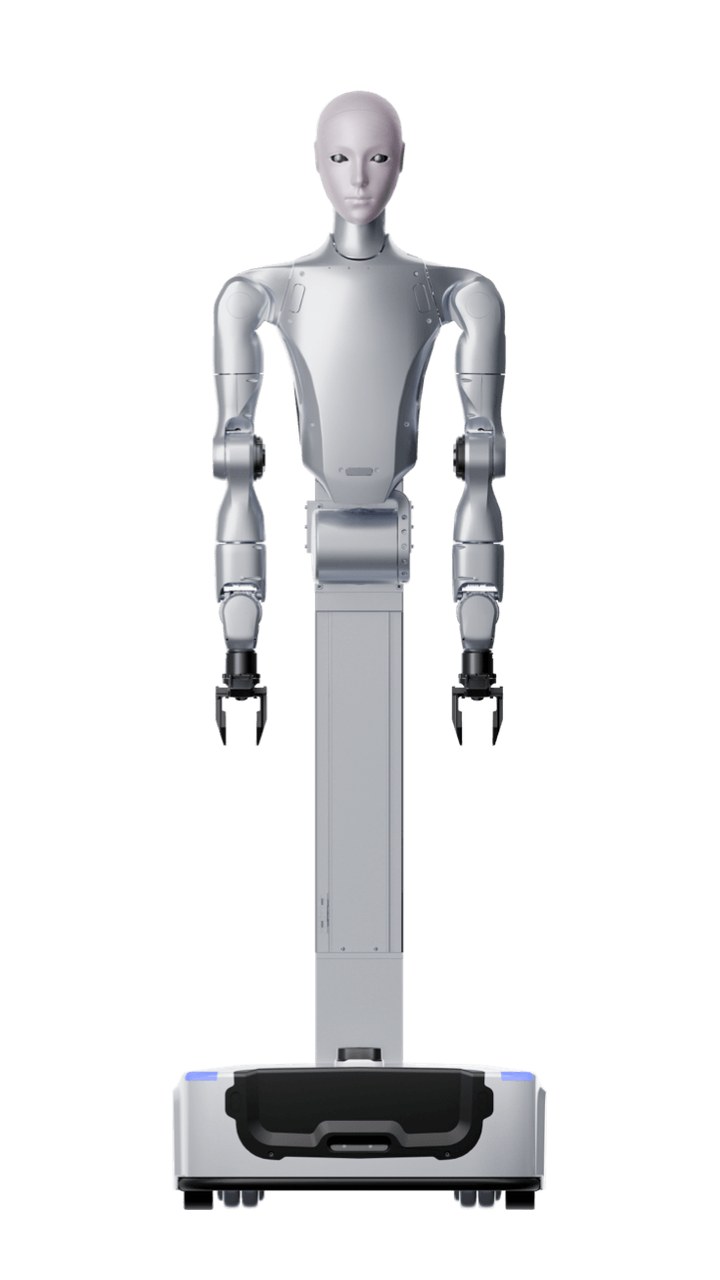
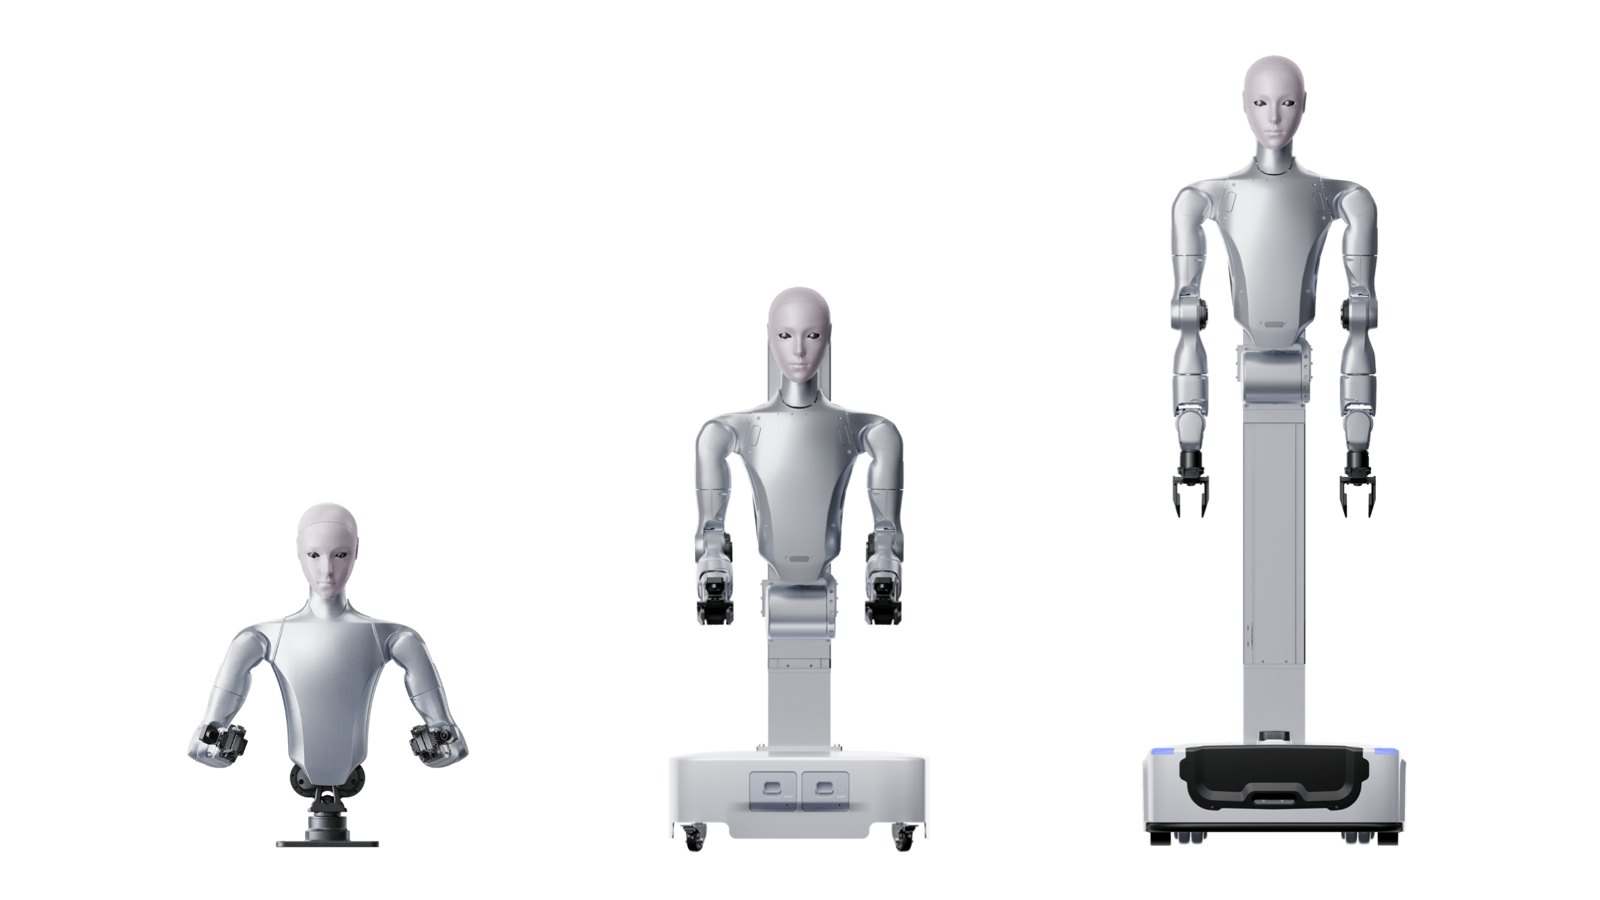
The H2-D does not walk. It is an H2 upper body (two arms, a pitching waist and a head) carried on a lifting column and a chassis instead of legs, which Unitree positions for industrial operations, commercial services, research and development, and embodied-intelligence training. If you need a humanoid that walks, choose the Unitree H2 or the H2-X. If you need the same arms at a fixed station, the H2-A sits on a fixed base and has a 3-DOF waist (yaw, pitch and roll) in place of the lifting column and deep pitch. Pictured left to right: H2-A (fixed base), H2-D Standard, H2-D Flagship.
Standard or Flagship: Manual-Move or Mobile Chassis
Same upper body. Two ways to position it.

Standard or Flagship: Manual-Move or Mobile Chassis

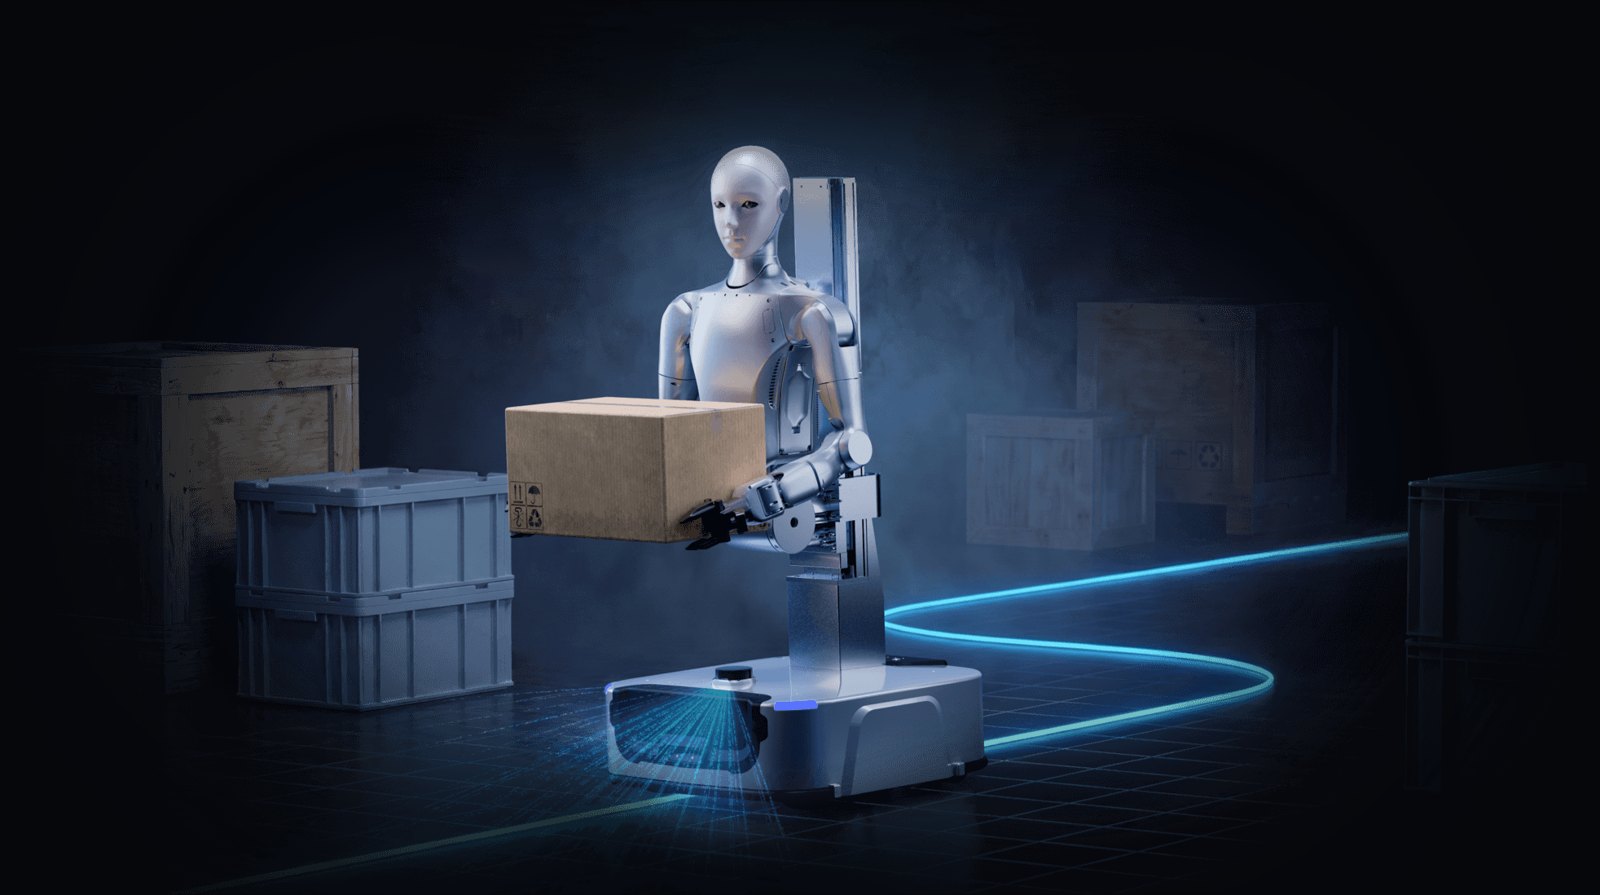
Standard builds sit on a manual-move chassis with no drive system: it is moved into position manually, the column lifts 0.36 m and rotates ±90°, and it runs 24/7 on external power. Flagship builds ride a mobile chassis with dual-wheel differential drive at up to 1.5 m/s, 360° turns in place and a 0.46 m lift, on a quick-release 48 V 30 Ah (1.44 kWh) battery for approx. 5 hours. The Flagship chassis carries LiDAR, a depth camera, two collision sensors and two ultrasonic sensors, which Unitree lists for autonomous navigation and obstacle avoidance.
From the Floor to 2 Metres
Column lift plus 0° to 115° waist pitch.

From the Floor to 2 Metres

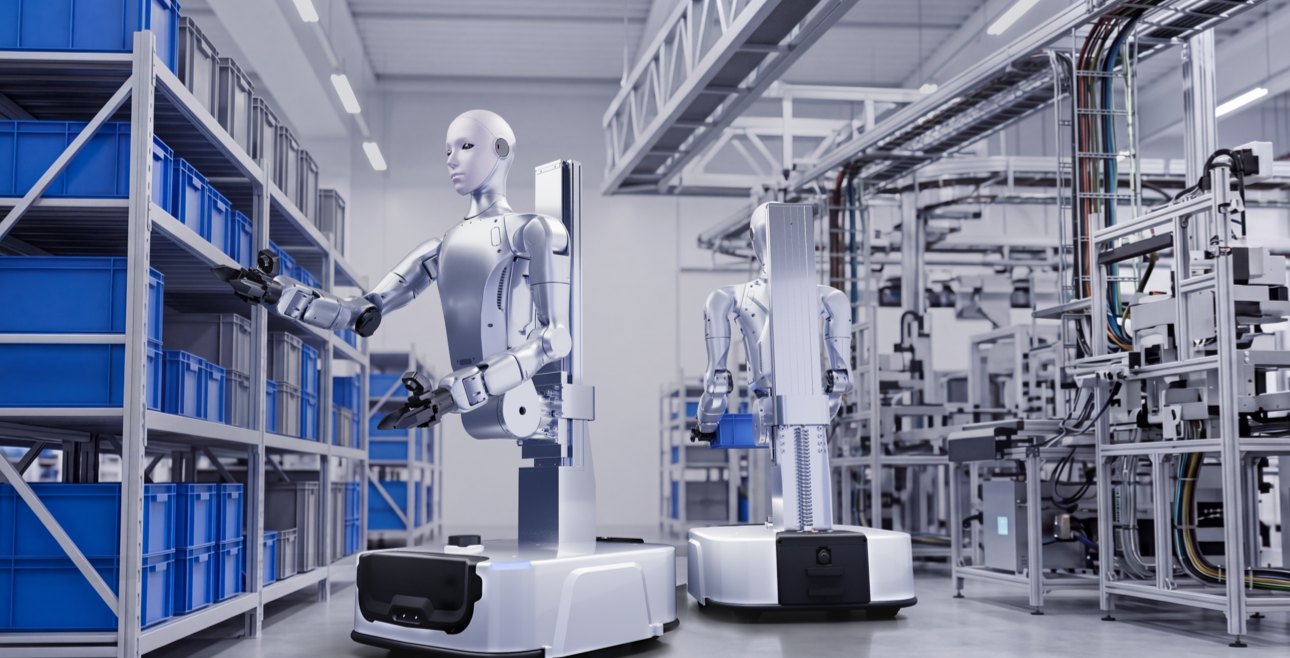
The waist pitches from 0° to 115° and the column lifts at up to 200 mm/s. Unitree says waist pitch and column lift together extend manipulation from ground level up to 2 metres, from floor-level picking to overhead handling. Each arm has seven joints, is rated for approx. 7 kg, peaks at approx. 15 kg and reaches approx. 0.6 m before the end effector. The wrists take grippers, three-finger hands or five-finger dexterous hands through a quick-change design, and every build ships with a pair.

Performance

H2-D at a Glance

19 / 20 DOF before end effectors, Standard / Flagship
~7 kg Rated payload per arm
2 m Max working height
115° Max waist pitch
0.36 m Lift travel (Standard)
0.46 m Lift travel (Flagship)
1.5 m/s Flagship top speed
~5 h Flagship runtime on battery
Unitree H2-D: view 1 Unitree H2-D: view 2
H2-D Parameters

Every build, side by side.

✓ included   ✗ not included
Pick up to 4 to compare
Specification H2-D Standard A ★ H2-D Standard F H2-D Standard B H2-D Standard G H2-D Standard C H2-D Standard H H2-D Flagship A H2-D Standard I H2-D Standard D H2-D Flagship F H2-D Standard E H2-D Flagship B H2-D Flagship G H2-D Flagship C H2-D Flagship H H2-D Standard M H2-D Flagship I H2-D Standard J H2-D Flagship D H2-D Flagship E H2-D Standard K H2-D Flagship M H2-D Flagship J H2-D Flagship K H2-D Standard L H2-D Flagship L
Specifications
Dimensions 1700 x 560 x 605 mm at max. column height 1700 x 560 x 605 mm at max. column height 1700 x 560 x 605 mm at max. column height 1700 x 560 x 605 mm at max. column height 1700 x 560 x 605 mm at max. column height 1700 x 560 x 605 mm at max. column height 1700 x 576 x 633 mm at max. column height 1700 x 560 x 605 mm at max. column height 1700 x 560 x 605 mm at max. column height 1700 x 576 x 633 mm at max. column height 1700 x 560 x 605 mm at max. column height 1700 x 576 x 633 mm at max. column height 1700 x 576 x 633 mm at max. column height 1700 x 576 x 633 mm at max. column height 1700 x 576 x 633 mm at max. column height 1700 x 560 x 605 mm at max. column height 1700 x 576 x 633 mm at max. column height 1700 x 560 x 605 mm at max. column height 1700 x 576 x 633 mm at max. column height 1700 x 576 x 633 mm at max. column height 1700 x 560 x 605 mm at max. column height 1700 x 576 x 633 mm at max. column height 1700 x 576 x 633 mm at max. column height 1700 x 576 x 633 mm at max. column height 1700 x 560 x 605 mm at max. column height 1700 x 576 x 633 mm at max. column height
Weight approx. 148 kg with battery approx. 148 kg with battery approx. 148 kg with battery approx. 148 kg with battery approx. 148 kg with battery approx. 148 kg with battery approx. 120 kg with battery approx. 148 kg with battery approx. 148 kg with battery approx. 120 kg with battery approx. 148 kg with battery approx. 120 kg with battery approx. 120 kg with battery approx. 120 kg with battery approx. 120 kg with battery approx. 148 kg with battery approx. 120 kg with battery approx. 148 kg with battery approx. 120 kg with battery approx. 120 kg with battery approx. 148 kg with battery approx. 120 kg with battery approx. 120 kg with battery approx. 120 kg with battery approx. 148 kg with battery approx. 120 kg with battery
Total DOF 21 (7 per arm, 1 waist, 2 head, 2 column, 1 per gripper) 31 (7 per arm, 1 waist, 2 head, 2 column, 6 per hand) 33 (7 per arm, 1 waist, 2 head, 2 column, 7 per hand) 31 (7 per arm, 1 waist, 2 head, 2 column, 6 per hand) 33 (7 per arm, 1 waist, 2 head, 2 column, 7 per hand) 31 (7 per arm, 1 waist, 2 head, 2 column, 6 per hand) 22 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 1 per gripper) 31 (7 per arm, 1 waist, 2 head, 2 column, 6 per hand) 51 (7 per arm, 1 waist, 2 head, 2 column, 16 per hand) 32 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 6 per hand) 51 (7 per arm, 1 waist, 2 head, 2 column, 16 per hand) 34 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 7 per hand) 32 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 6 per hand) 34 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 7 per hand) 32 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 6 per hand) 59 (7 per arm, 1 waist, 2 head, 2 column, 20 per hand) 32 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 6 per hand) 61 (7 per arm, 1 waist, 2 head, 2 column, 21 per hand) 52 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 16 per hand) 52 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 16 per hand) 61 (7 per arm, 1 waist, 2 head, 2 column, 21 per hand) 60 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 20 per hand) 62 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 21 per hand) 62 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 21 per hand) 61 (7 per arm, 1 waist, 2 head, 2 column, 21 per hand) 62 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 21 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector, approx. 0.62 m with gripper approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector, approx. 0.62 m with gripper approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector approx. 0.6 m excl. end effector
Lifting column 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base 0.46 m travel, up to 200 mm/s 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base 0.46 m travel, up to 200 mm/s 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base 0.46 m travel, up to 200 mm/s 0.46 m travel, up to 200 mm/s 0.46 m travel, up to 200 mm/s 0.46 m travel, up to 200 mm/s 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base 0.46 m travel, up to 200 mm/s 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base 0.46 m travel, up to 200 mm/s 0.46 m travel, up to 200 mm/s 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base 0.46 m travel, up to 200 mm/s 0.46 m travel, up to 200 mm/s 0.46 m travel, up to 200 mm/s 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base 0.46 m travel, up to 200 mm/s
Waist 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115° 1 DOF pitch, 0° to 115°
Chassis Manual-move chassis, no drive system Manual-move chassis, no drive system Manual-move chassis, no drive system Manual-move chassis, no drive system Manual-move chassis, no drive system Manual-move chassis, no drive system Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter Manual-move chassis, no drive system Manual-move chassis, no drive system Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter Manual-move chassis, no drive system Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter Manual-move chassis, no drive system Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter Manual-move chassis, no drive system Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter Manual-move chassis, no drive system Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter Manual-move chassis, no drive system Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter
Chassis sensors None None None None None None LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors None None LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors None LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors None LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors None LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors None LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors None LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors
Power External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh) External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh) External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh) External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh) External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh) External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh) Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh) External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh) Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh) Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh) Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh) Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh) Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh) Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option
End effectors 2 x Dex1-1 Standard two-finger grippers with wrist cameras 2 x BrainCo Revo 2 Basic five-finger hands with wrist cameras 2 x Dex3-1 three-finger force-controlled hands with wrist cameras 2 x BrainCo Revo 2 Touch five-finger hands with wrist cameras 2 x Dex3-1 three-finger force-controlled hands with wrist cameras 2 x Inspire DFQ five-finger hands with wrist cameras 2 x Dex1-1 Advanced two-finger grippers with wrist cameras 2 x Inspire E2 five-finger hands with wrist cameras 2 x Dex5-1 five-finger hands with wrist cameras 2 x BrainCo Revo 2 Basic five-finger hands with wrist cameras 2 x Dex5-1P five-finger hands with wrist cameras 2 x Dex3-1 three-finger force-controlled hands with wrist cameras 2 x BrainCo Revo 2 Touch five-finger hands with wrist cameras 2 x Dex3-1 three-finger force-controlled hands with wrist cameras 2 x Inspire DFQ five-finger hands with wrist cameras 2 x WUJI Hand 2 five-finger hands with wrist cameras 2 x Inspire E2 five-finger hands with wrist cameras 2 x BrainCo Revo 3 U21 five-finger hands with wrist cameras 2 x Dex5-1 five-finger hands with wrist cameras 2 x Dex5-1P five-finger hands with wrist cameras 2 x BrainCo Revo 3 U21T five-finger hands with wrist cameras 2 x WUJI Hand 2 five-finger hands with wrist cameras 2 x BrainCo Revo 3 U21 five-finger hands with wrist cameras 2 x BrainCo Revo 3 U21T five-finger hands with wrist cameras 2 x BrainCo Revo 3 U21VT five-finger hands with wrist cameras 2 x BrainCo Revo 3 U21VT five-finger hands with wrist cameras
End-effector specs 90 mm stroke, 5 to 120 N adjustable grip, 0.24 s full-stroke close, 20 kg form-closure / 5 kg friction load, 550 g 6 DOF, 11 joints, 383 g, 50 N grip, 15 N per finger, 0.1° repeatability 7 DOF (thumb 3, index 2, middle 2), approx. 650 g, 175 x 88 x 77 mm, 12 to 58 V, USB 6 DOF, 11 joints, 383 g, 50 N grip, 15 N per finger, 0.1° repeatability 7 DOF (thumb 3, index 2, middle 2), approx. 650 g, 175 x 88 x 77 mm, 12 to 58 V, USB 6 DOF, 12 joints, 6 N thumb and 4 N finger grip, ±0.20 mm repeatability, 570°/s finger flexion 90 mm stroke, 5 to 120 N adjustable grip, 0.24 s full-stroke close, 20 kg form-closure / 5 kg friction load, 550 g 6 DOF, 12 joints, approx. 800 g, 30 N thumb and 28 N finger grip, 0.8 s palm close, 24 V 16 DOF, 12 micro force-controlled joints, 10 N fingertip force, ±1 mm repeatability, 10 mm min grasp 6 DOF, 11 joints, 383 g, 50 N grip, 15 N per finger, 0.1° repeatability 16 DOF, 12 micro force-controlled joints, 10 N fingertip force, ±1 mm repeatability, 10 mm min grasp 7 DOF (thumb 3, index 2, middle 2), approx. 650 g, 175 x 88 x 77 mm, 12 to 58 V, USB 6 DOF, 11 joints, 383 g, 50 N grip, 15 N per finger, 0.1° repeatability 7 DOF (thumb 3, index 2, middle 2), approx. 650 g, 175 x 88 x 77 mm, 12 to 58 V, USB 6 DOF, 12 joints, 6 N thumb and 4 N finger grip, ±0.20 mm repeatability, 570°/s finger flexion 20 active DOF, direct-drive back-drivable joints, at least 15 N peak fingertip force, 1000 Hz control, 16 to 58 V 6 DOF, 12 joints, approx. 800 g, 30 N thumb and 28 N finger grip, 0.8 s palm close, 24 V 21 active DOF (4 per finger, 5 thumb), 70 N palm grip, 20 N fingertip, 3 Hz open/close, 500 Hz control, 12 to 80 V 16 DOF, 12 micro force-controlled joints, 10 N fingertip force, ±1 mm repeatability, 10 mm min grasp 16 DOF, 12 micro force-controlled joints, 10 N fingertip force, ±1 mm repeatability, 10 mm min grasp 21 active DOF (4 per finger, 5 thumb), 70 N palm grip, 20 N fingertip, 3 Hz open/close, 500 Hz control, 12 to 80 V 20 active DOF, direct-drive back-drivable joints, at least 15 N peak fingertip force, 1000 Hz control, 16 to 58 V 21 active DOF (4 per finger, 5 thumb), 70 N palm grip, 20 N fingertip, 3 Hz open/close, 500 Hz control, 12 to 80 V 21 active DOF (4 per finger, 5 thumb), 70 N palm grip, 20 N fingertip, 3 Hz open/close, 500 Hz control, 12 to 80 V 21 active DOF (4 per finger, 5 thumb), 70 N palm grip, 20 N fingertip, 3 Hz open/close, 500 Hz control, 12 to 80 V 21 active DOF (4 per finger, 5 thumb), 70 N palm grip, 20 N fingertip, 3 Hz open/close, 500 Hz control, 12 to 80 V
Tactile sensing None None None Pressure, friction, direction and proximity 33 sensors per hand None None 17 sensors per hand, 0 to 30 N, accuracy within 5% FS None None 12 sensor arrays (94 pressure sensors) per hand None Pressure, friction, direction and proximity 33 sensors per hand None None 17 sensors per hand, 0 to 30 N, accuracy within 5% FS None None 12 sensor arrays (94 pressure sensors) per hand Full palm, 0.01 N resolution None None Full palm, 0.01 N resolution Full palm, 0.01 N resolution, plus visuo-tactile, 130 μm min deformation Full palm, 0.01 N resolution, plus visuo-tactile, 130 μm min deformation
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080 Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4) Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2 Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, external power supply Handheld remote, external power supply Handheld remote, external power supply Handheld remote, external power supply Handheld remote, external power supply Handheld remote, external power supply Handheld remote, visualization PC, charging pile kit Handheld remote, external power supply Handheld remote, external power supply Handheld remote, visualization PC, charging pile kit Handheld remote, external power supply Handheld remote, visualization PC, charging pile kit Handheld remote, visualization PC, charging pile kit Handheld remote, visualization PC, charging pile kit Handheld remote, visualization PC, charging pile kit Handheld remote, external power supply Handheld remote, visualization PC, charging pile kit Handheld remote, external power supply Handheld remote, visualization PC, charging pile kit Handheld remote, visualization PC, charging pile kit Handheld remote, external power supply Handheld remote, visualization PC, charging pile kit Handheld remote, visualization PC, charging pile kit Handheld remote, visualization PC, charging pile kit Handheld remote, external power supply Handheld remote, visualization PC, charging pile kit
Warranty 12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months
Price ex VAT R 574,000 R 686,000 R 733,250 R 756,000 R 768,250 R 768,250 R 827,750 R 838,250 R 908,250 R 939,750 R 960,750 R 987,000 R 1,009,750 R 1,022,000 R 1,022,000 R 1,083,250 R 1,092,000 R 1,153,250 R 1,162,000 R 1,214,500 R 1,328,250 R 1,337,000 R 1,407,000 R 1,582,000 R 1,783,250 R 2,037,000
H2-D Standard A ★ R 574,000
Specifications
Dimensions 1700 x 560 x 605 mm at max. column height
Weight approx. 148 kg with battery
Total DOF 21 (7 per arm, 1 waist, 2 head, 2 column, 1 per gripper)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector, approx. 0.62 m with gripper
Lifting column 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base
Waist 1 DOF pitch, 0° to 115°
Chassis Manual-move chassis, no drive system
Chassis sensors None
Power External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh)
End effectors 2 x Dex1-1 Standard two-finger grippers with wrist cameras
End-effector specs 90 mm stroke, 5 to 120 N adjustable grip, 0.24 s full-stroke close, 20 kg form-closure / 5 kg friction load, 550 g
Tactile sensing None
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, external power supply
Warranty12 months
Configure this build
H2-D Standard F R 686,000
Specifications
Dimensions 1700 x 560 x 605 mm at max. column height
Weight approx. 148 kg with battery
Total DOF 31 (7 per arm, 1 waist, 2 head, 2 column, 6 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base
Waist 1 DOF pitch, 0° to 115°
Chassis Manual-move chassis, no drive system
Chassis sensors None
Power External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh)
End effectors 2 x BrainCo Revo 2 Basic five-finger hands with wrist cameras
End-effector specs 6 DOF, 11 joints, 383 g, 50 N grip, 15 N per finger, 0.1° repeatability
Tactile sensing None
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, external power supply
Warranty12 months
Configure this build
H2-D Standard B R 733,250
Specifications
Dimensions 1700 x 560 x 605 mm at max. column height
Weight approx. 148 kg with battery
Total DOF 33 (7 per arm, 1 waist, 2 head, 2 column, 7 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base
Waist 1 DOF pitch, 0° to 115°
Chassis Manual-move chassis, no drive system
Chassis sensors None
Power External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh)
End effectors 2 x Dex3-1 three-finger force-controlled hands with wrist cameras
End-effector specs 7 DOF (thumb 3, index 2, middle 2), approx. 650 g, 175 x 88 x 77 mm, 12 to 58 V, USB
Tactile sensing None
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, external power supply
Warranty12 months
Configure this build
H2-D Standard G R 756,000
Specifications
Dimensions 1700 x 560 x 605 mm at max. column height
Weight approx. 148 kg with battery
Total DOF 31 (7 per arm, 1 waist, 2 head, 2 column, 6 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base
Waist 1 DOF pitch, 0° to 115°
Chassis Manual-move chassis, no drive system
Chassis sensors None
Power External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh)
End effectors 2 x BrainCo Revo 2 Touch five-finger hands with wrist cameras
End-effector specs 6 DOF, 11 joints, 383 g, 50 N grip, 15 N per finger, 0.1° repeatability
Tactile sensing Pressure, friction, direction and proximity
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, external power supply
Warranty12 months
Configure this build
H2-D Standard C R 768,250
Specifications
Dimensions 1700 x 560 x 605 mm at max. column height
Weight approx. 148 kg with battery
Total DOF 33 (7 per arm, 1 waist, 2 head, 2 column, 7 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base
Waist 1 DOF pitch, 0° to 115°
Chassis Manual-move chassis, no drive system
Chassis sensors None
Power External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh)
End effectors 2 x Dex3-1 three-finger force-controlled hands with wrist cameras
End-effector specs 7 DOF (thumb 3, index 2, middle 2), approx. 650 g, 175 x 88 x 77 mm, 12 to 58 V, USB
Tactile sensing 33 sensors per hand
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, external power supply
Warranty12 months
Configure this build
H2-D Standard H R 768,250
Specifications
Dimensions 1700 x 560 x 605 mm at max. column height
Weight approx. 148 kg with battery
Total DOF 31 (7 per arm, 1 waist, 2 head, 2 column, 6 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base
Waist 1 DOF pitch, 0° to 115°
Chassis Manual-move chassis, no drive system
Chassis sensors None
Power External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh)
End effectors 2 x Inspire DFQ five-finger hands with wrist cameras
End-effector specs 6 DOF, 12 joints, 6 N thumb and 4 N finger grip, ±0.20 mm repeatability, 570°/s finger flexion
Tactile sensing None
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, external power supply
Warranty12 months
Configure this build
H2-D Flagship A R 827,750
Specifications
Dimensions 1700 x 576 x 633 mm at max. column height
Weight approx. 120 kg with battery
Total DOF 22 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 1 per gripper)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector, approx. 0.62 m with gripper
Lifting column 0.46 m travel, up to 200 mm/s
Waist 1 DOF pitch, 0° to 115°
Chassis Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter
Chassis sensors LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors
Power Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option
End effectors 2 x Dex1-1 Advanced two-finger grippers with wrist cameras
End-effector specs 90 mm stroke, 5 to 120 N adjustable grip, 0.24 s full-stroke close, 20 kg form-closure / 5 kg friction load, 550 g
Tactile sensing None
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, visualization PC, charging pile kit
Warranty12 months
Configure this build
H2-D Standard I R 838,250
Specifications
Dimensions 1700 x 560 x 605 mm at max. column height
Weight approx. 148 kg with battery
Total DOF 31 (7 per arm, 1 waist, 2 head, 2 column, 6 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base
Waist 1 DOF pitch, 0° to 115°
Chassis Manual-move chassis, no drive system
Chassis sensors None
Power External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh)
End effectors 2 x Inspire E2 five-finger hands with wrist cameras
End-effector specs 6 DOF, 12 joints, approx. 800 g, 30 N thumb and 28 N finger grip, 0.8 s palm close, 24 V
Tactile sensing 17 sensors per hand, 0 to 30 N, accuracy within 5% FS
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, external power supply
Warranty12 months
Configure this build
H2-D Standard D R 908,250
Specifications
Dimensions 1700 x 560 x 605 mm at max. column height
Weight approx. 148 kg with battery
Total DOF 51 (7 per arm, 1 waist, 2 head, 2 column, 16 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base
Waist 1 DOF pitch, 0° to 115°
Chassis Manual-move chassis, no drive system
Chassis sensors None
Power External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh)
End effectors 2 x Dex5-1 five-finger hands with wrist cameras
End-effector specs 16 DOF, 12 micro force-controlled joints, 10 N fingertip force, ±1 mm repeatability, 10 mm min grasp
Tactile sensing None
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, external power supply
Warranty12 months
Configure this build
H2-D Flagship F R 939,750
Specifications
Dimensions 1700 x 576 x 633 mm at max. column height
Weight approx. 120 kg with battery
Total DOF 32 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 6 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.46 m travel, up to 200 mm/s
Waist 1 DOF pitch, 0° to 115°
Chassis Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter
Chassis sensors LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors
Power Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option
End effectors 2 x BrainCo Revo 2 Basic five-finger hands with wrist cameras
End-effector specs 6 DOF, 11 joints, 383 g, 50 N grip, 15 N per finger, 0.1° repeatability
Tactile sensing None
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, visualization PC, charging pile kit
Warranty12 months
Configure this build
H2-D Standard E R 960,750
Specifications
Dimensions 1700 x 560 x 605 mm at max. column height
Weight approx. 148 kg with battery
Total DOF 51 (7 per arm, 1 waist, 2 head, 2 column, 16 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base
Waist 1 DOF pitch, 0° to 115°
Chassis Manual-move chassis, no drive system
Chassis sensors None
Power External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh)
End effectors 2 x Dex5-1P five-finger hands with wrist cameras
End-effector specs 16 DOF, 12 micro force-controlled joints, 10 N fingertip force, ±1 mm repeatability, 10 mm min grasp
Tactile sensing 12 sensor arrays (94 pressure sensors) per hand
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, external power supply
Warranty12 months
Configure this build
H2-D Flagship B R 987,000
Specifications
Dimensions 1700 x 576 x 633 mm at max. column height
Weight approx. 120 kg with battery
Total DOF 34 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 7 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.46 m travel, up to 200 mm/s
Waist 1 DOF pitch, 0° to 115°
Chassis Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter
Chassis sensors LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors
Power Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option
End effectors 2 x Dex3-1 three-finger force-controlled hands with wrist cameras
End-effector specs 7 DOF (thumb 3, index 2, middle 2), approx. 650 g, 175 x 88 x 77 mm, 12 to 58 V, USB
Tactile sensing None
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, visualization PC, charging pile kit
Warranty12 months
Configure this build
H2-D Flagship G R 1,009,750
Specifications
Dimensions 1700 x 576 x 633 mm at max. column height
Weight approx. 120 kg with battery
Total DOF 32 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 6 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.46 m travel, up to 200 mm/s
Waist 1 DOF pitch, 0° to 115°
Chassis Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter
Chassis sensors LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors
Power Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option
End effectors 2 x BrainCo Revo 2 Touch five-finger hands with wrist cameras
End-effector specs 6 DOF, 11 joints, 383 g, 50 N grip, 15 N per finger, 0.1° repeatability
Tactile sensing Pressure, friction, direction and proximity
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, visualization PC, charging pile kit
Warranty12 months
Configure this build
H2-D Flagship C R 1,022,000
Specifications
Dimensions 1700 x 576 x 633 mm at max. column height
Weight approx. 120 kg with battery
Total DOF 34 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 7 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.46 m travel, up to 200 mm/s
Waist 1 DOF pitch, 0° to 115°
Chassis Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter
Chassis sensors LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors
Power Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option
End effectors 2 x Dex3-1 three-finger force-controlled hands with wrist cameras
End-effector specs 7 DOF (thumb 3, index 2, middle 2), approx. 650 g, 175 x 88 x 77 mm, 12 to 58 V, USB
Tactile sensing 33 sensors per hand
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, visualization PC, charging pile kit
Warranty12 months
Configure this build
H2-D Flagship H R 1,022,000
Specifications
Dimensions 1700 x 576 x 633 mm at max. column height
Weight approx. 120 kg with battery
Total DOF 32 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 6 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.46 m travel, up to 200 mm/s
Waist 1 DOF pitch, 0° to 115°
Chassis Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter
Chassis sensors LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors
Power Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option
End effectors 2 x Inspire DFQ five-finger hands with wrist cameras
End-effector specs 6 DOF, 12 joints, 6 N thumb and 4 N finger grip, ±0.20 mm repeatability, 570°/s finger flexion
Tactile sensing None
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, visualization PC, charging pile kit
Warranty12 months
Configure this build
H2-D Standard M R 1,083,250
Specifications
Dimensions 1700 x 560 x 605 mm at max. column height
Weight approx. 148 kg with battery
Total DOF 59 (7 per arm, 1 waist, 2 head, 2 column, 20 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base
Waist 1 DOF pitch, 0° to 115°
Chassis Manual-move chassis, no drive system
Chassis sensors None
Power External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh)
End effectors 2 x WUJI Hand 2 five-finger hands with wrist cameras
End-effector specs 20 active DOF, direct-drive back-drivable joints, at least 15 N peak fingertip force, 1000 Hz control, 16 to 58 V
Tactile sensing None
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, external power supply
Warranty12 months
Configure this build
H2-D Flagship I R 1,092,000
Specifications
Dimensions 1700 x 576 x 633 mm at max. column height
Weight approx. 120 kg with battery
Total DOF 32 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 6 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.46 m travel, up to 200 mm/s
Waist 1 DOF pitch, 0° to 115°
Chassis Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter
Chassis sensors LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors
Power Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option
End effectors 2 x Inspire E2 five-finger hands with wrist cameras
End-effector specs 6 DOF, 12 joints, approx. 800 g, 30 N thumb and 28 N finger grip, 0.8 s palm close, 24 V
Tactile sensing 17 sensors per hand, 0 to 30 N, accuracy within 5% FS
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, visualization PC, charging pile kit
Warranty12 months
Configure this build
H2-D Standard J R 1,153,250
Specifications
Dimensions 1700 x 560 x 605 mm at max. column height
Weight approx. 148 kg with battery
Total DOF 61 (7 per arm, 1 waist, 2 head, 2 column, 21 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base
Waist 1 DOF pitch, 0° to 115°
Chassis Manual-move chassis, no drive system
Chassis sensors None
Power External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh)
End effectors 2 x BrainCo Revo 3 U21 five-finger hands with wrist cameras
End-effector specs 21 active DOF (4 per finger, 5 thumb), 70 N palm grip, 20 N fingertip, 3 Hz open/close, 500 Hz control, 12 to 80 V
Tactile sensing None
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, external power supply
Warranty12 months
Configure this build
H2-D Flagship D R 1,162,000
Specifications
Dimensions 1700 x 576 x 633 mm at max. column height
Weight approx. 120 kg with battery
Total DOF 52 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 16 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.46 m travel, up to 200 mm/s
Waist 1 DOF pitch, 0° to 115°
Chassis Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter
Chassis sensors LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors
Power Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option
End effectors 2 x Dex5-1 five-finger hands with wrist cameras
End-effector specs 16 DOF, 12 micro force-controlled joints, 10 N fingertip force, ±1 mm repeatability, 10 mm min grasp
Tactile sensing None
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, visualization PC, charging pile kit
Warranty12 months
Configure this build
H2-D Flagship E R 1,214,500
Specifications
Dimensions 1700 x 576 x 633 mm at max. column height
Weight approx. 120 kg with battery
Total DOF 52 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 16 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.46 m travel, up to 200 mm/s
Waist 1 DOF pitch, 0° to 115°
Chassis Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter
Chassis sensors LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors
Power Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option
End effectors 2 x Dex5-1P five-finger hands with wrist cameras
End-effector specs 16 DOF, 12 micro force-controlled joints, 10 N fingertip force, ±1 mm repeatability, 10 mm min grasp
Tactile sensing 12 sensor arrays (94 pressure sensors) per hand
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, visualization PC, charging pile kit
Warranty12 months
Configure this build
H2-D Standard K R 1,328,250
Specifications
Dimensions 1700 x 560 x 605 mm at max. column height
Weight approx. 148 kg with battery
Total DOF 61 (7 per arm, 1 waist, 2 head, 2 column, 21 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base
Waist 1 DOF pitch, 0° to 115°
Chassis Manual-move chassis, no drive system
Chassis sensors None
Power External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh)
End effectors 2 x BrainCo Revo 3 U21T five-finger hands with wrist cameras
End-effector specs 21 active DOF (4 per finger, 5 thumb), 70 N palm grip, 20 N fingertip, 3 Hz open/close, 500 Hz control, 12 to 80 V
Tactile sensing Full palm, 0.01 N resolution
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, external power supply
Warranty12 months
Configure this build
H2-D Flagship M R 1,337,000
Specifications
Dimensions 1700 x 576 x 633 mm at max. column height
Weight approx. 120 kg with battery
Total DOF 60 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 20 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.46 m travel, up to 200 mm/s
Waist 1 DOF pitch, 0° to 115°
Chassis Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter
Chassis sensors LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors
Power Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option
End effectors 2 x WUJI Hand 2 five-finger hands with wrist cameras
End-effector specs 20 active DOF, direct-drive back-drivable joints, at least 15 N peak fingertip force, 1000 Hz control, 16 to 58 V
Tactile sensing None
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, visualization PC, charging pile kit
Warranty12 months
Configure this build
H2-D Flagship J R 1,407,000
Specifications
Dimensions 1700 x 576 x 633 mm at max. column height
Weight approx. 120 kg with battery
Total DOF 62 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 21 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.46 m travel, up to 200 mm/s
Waist 1 DOF pitch, 0° to 115°
Chassis Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter
Chassis sensors LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors
Power Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option
End effectors 2 x BrainCo Revo 3 U21 five-finger hands with wrist cameras
End-effector specs 21 active DOF (4 per finger, 5 thumb), 70 N palm grip, 20 N fingertip, 3 Hz open/close, 500 Hz control, 12 to 80 V
Tactile sensing None
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, visualization PC, charging pile kit
Warranty12 months
Configure this build
H2-D Flagship K R 1,582,000
Specifications
Dimensions 1700 x 576 x 633 mm at max. column height
Weight approx. 120 kg with battery
Total DOF 62 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 21 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.46 m travel, up to 200 mm/s
Waist 1 DOF pitch, 0° to 115°
Chassis Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter
Chassis sensors LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors
Power Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option
End effectors 2 x BrainCo Revo 3 U21T five-finger hands with wrist cameras
End-effector specs 21 active DOF (4 per finger, 5 thumb), 70 N palm grip, 20 N fingertip, 3 Hz open/close, 500 Hz control, 12 to 80 V
Tactile sensing Full palm, 0.01 N resolution
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, visualization PC, charging pile kit
Warranty12 months
Configure this build
H2-D Standard L R 1,783,250
Specifications
Dimensions 1700 x 560 x 605 mm at max. column height
Weight approx. 148 kg with battery
Total DOF 61 (7 per arm, 1 waist, 2 head, 2 column, 21 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.36 m travel, up to 200 mm/s; column also rotates ±90° at the base
Waist 1 DOF pitch, 0° to 115°
Chassis Manual-move chassis, no drive system
Chassis sensors None
Power External supply for 24/7 use; 2 swappable base batteries for energy storage and back-EMF only; base battery 48 V 18 Ah (864 Wh)
End effectors 2 x BrainCo Revo 3 U21VT five-finger hands with wrist cameras
End-effector specs 21 active DOF (4 per finger, 5 thumb), 70 N palm grip, 20 N fingertip, 3 Hz open/close, 500 Hz control, 12 to 80 V
Tactile sensing Full palm, 0.01 N resolution, plus visuo-tactile, 130 μm min deformation
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, external power supply
Warranty12 months
Configure this build
H2-D Flagship L R 2,037,000
Specifications
Dimensions 1700 x 576 x 633 mm at max. column height
Weight approx. 120 kg with battery
Total DOF 62 (7 per arm, 1 waist, 2 head, 1 column, 2 base, 21 per hand)
Arm payload approx. 7 kg rated, approx. 15 kg peak per arm
Arm reach approx. 0.6 m excl. end effector
Lifting column 0.46 m travel, up to 200 mm/s
Waist 1 DOF pitch, 0° to 115°
Chassis Mobile chassis: dual-wheel servo differential drive, up to 1.5 m/s, 360° turn in place, approx. 0.75 m turning diameter
Chassis sensors LiDAR, depth camera, 2 collision sensors, 2 ultrasonic sensors
Power Quick-release 48 V 30 Ah (1.44 kWh) base battery, approx. 5 h, swap or auto recharge; external power option
End effectors 2 x BrainCo Revo 3 U21VT five-finger hands with wrist cameras
End-effector specs 21 active DOF (4 per finger, 5 thumb), 70 N palm grip, 20 N fingertip, 3 Hz open/close, 500 Hz control, 12 to 80 V
Tactile sensing Full palm, 0.01 N resolution, plus visuo-tactile, 130 μm min deformation
Cameras Wide-angle binocular head camera; 2 x RGB wrist cameras, 1920×1080
Compute Intel Core i5 (platform) and Core i7 (development); optional Jetson Thor (PC3), Core i7 or Orin NX (PC4)
Connectivity Wi-Fi 6, Bluetooth 5.2
In the box Handheld remote, visualization PC, charging pile kit
Warranty12 months
Configure this build

Specifications follow Unitree factory data and may change with firmware and hardware revisions. Rand prices exclude VAT, airfreight, customs and delivery, itemised at checkout. ★ default configuration.

Configure & Order

Build your H2-D.

1. Configuration
2. Add accessories
Questions

H2-D in South Africa: the practical answers.

Pricing starts at R 574,000 ex VAT across 26 configurations. All prices are in Rand, ex VAT, and are confirmed on your quotation.
We handle airfreight from the factory, customs clearance and insured local delivery to anywhere in South Africa. These landed costs are itemised on your order before you pay. Typical lead time is 4 to 6 weeks from payment confirmation.
Yes: 12 months depending on configuration, backed by Unitree and handled locally by MCM Robotics as the official South African distributor. Repairs, genuine parts and firmware support run through us.
Add your build to the cart and request a quote: a PDF quotation with our FNB banking details arrives by email within a minute. Orders confirm on EFT receipt, and we support institutional and tender paperwork.
EDU and developer configurations expose Unitree's full SDK: low-level joint control, perception streams and simulation environments (ROS2, Isaac Sim, MuJoCo). See the Education page for curriculum support and tier guidance.
Accessories

Extend the H2-D.

All accessories →
Unitree H2 Handheld Remote
H2 Extras Unitree H2 Handheld Remote R 4,375
H2 Dex1-1 Industrial Gripper (Standard)
H2 Dex1-1 Plus Gripper (Advanced Version)
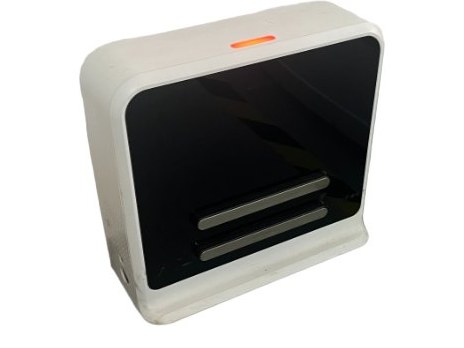
Wheeled Base Charging Pile Kit
G1-D Extras Wheeled Base Charging Pile Kit R 17,500