Unitree R1 Robotic Arm
Robotic Arm
UNIT://R1-ROBOTIC-ARM CONFIGS: 20 LIVE ZAR PRICING

R1 Robotic Arm .

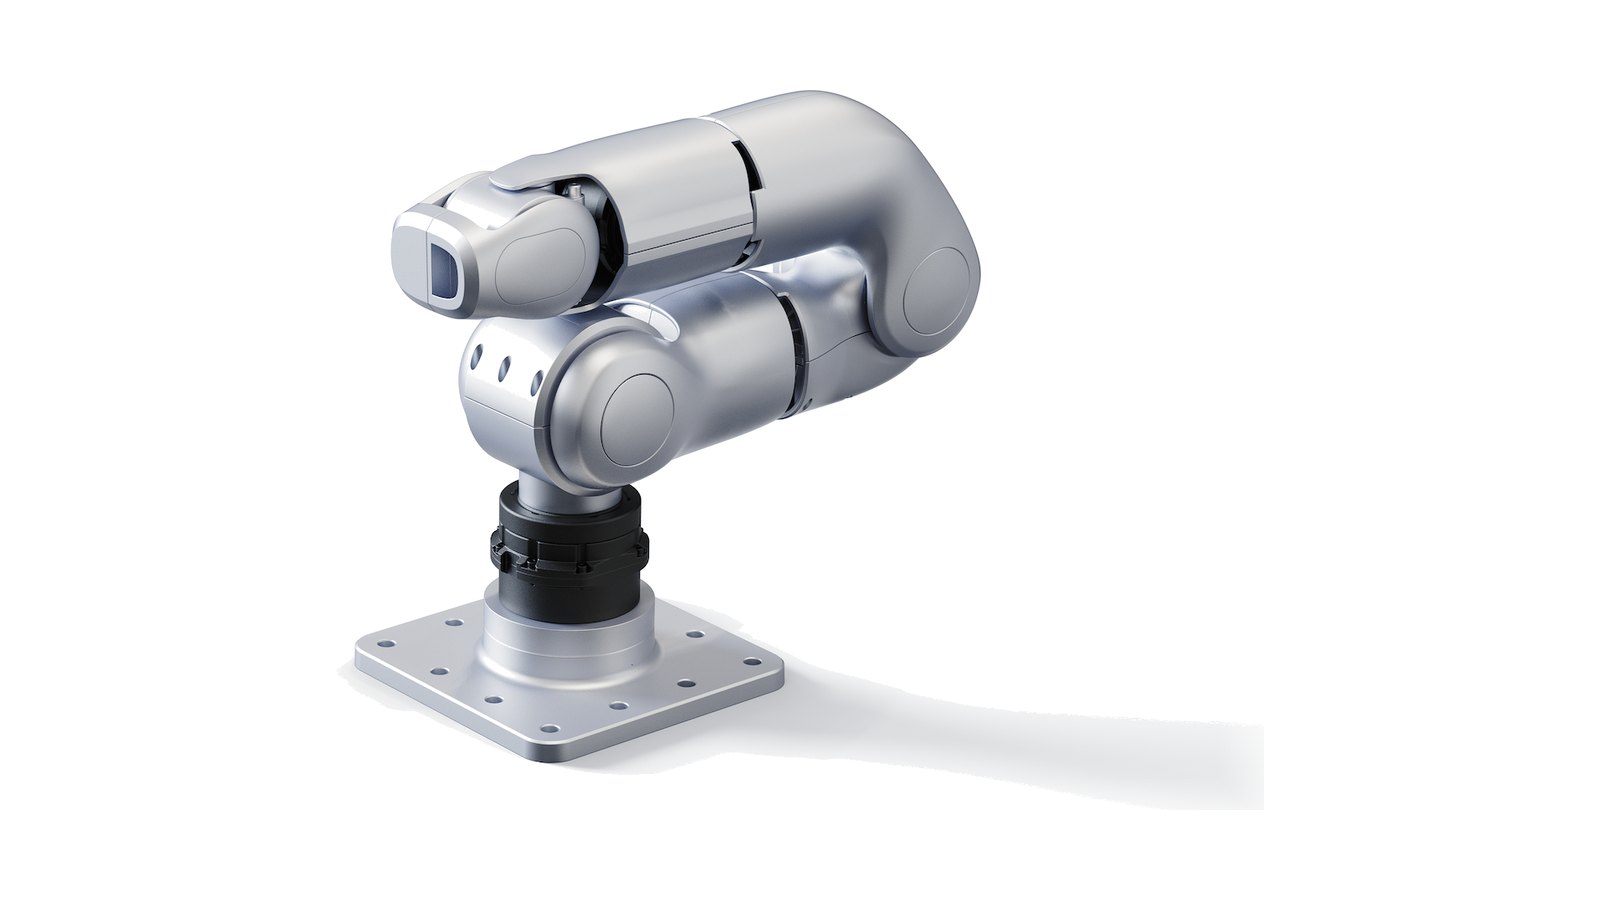
A standalone 7-DOF robotic arm in the same class as the Z1. Not a replacement arm for the R1 humanoid.

from R 28,875EX VAT 20 configurations Warranty 12 months

Research-grade machinery for trained adult operators, not a toy. Read the Product Safety Notice before you order.

R1 Robotic Arm — Key figures FACTORY DATA
In the box R1 Robotic Arm, 7-DOF
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Arm only, no gripper or hand fitted. No RGB camera.
Total DOF 7
Mount Flat base plate
Wrist camera No
Not an R1 spare arm
A standalone arm in the Z1 class.

Not an R1 spare arm

The R1 Robotic Arm shares its name with Unitree's R1 humanoid, but it is sold and supplied as its own product: a complete 7-DOF arm that you mount on a bench, in a fixed cell or on a mobile base. It is not sold or supported as a replacement arm for the R1 humanoid. If you are comparing arms, compare it with the Unitree Z1.
Seven joints, your choice of hand
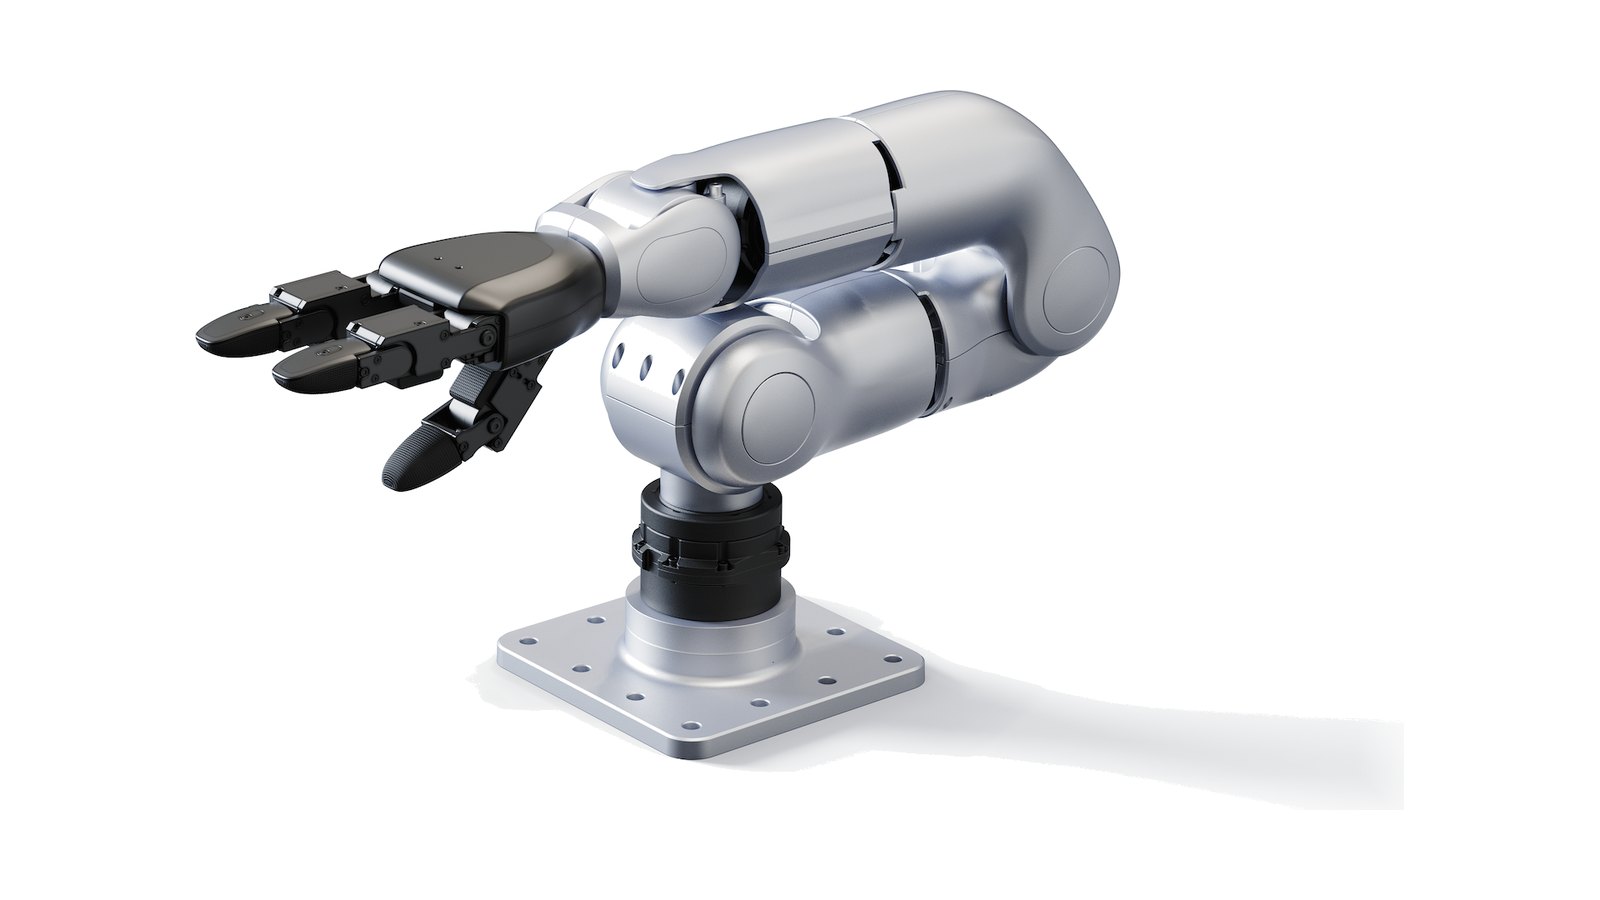
Arm only, gripper or dexterous hand.

Seven joints, your choice of hand

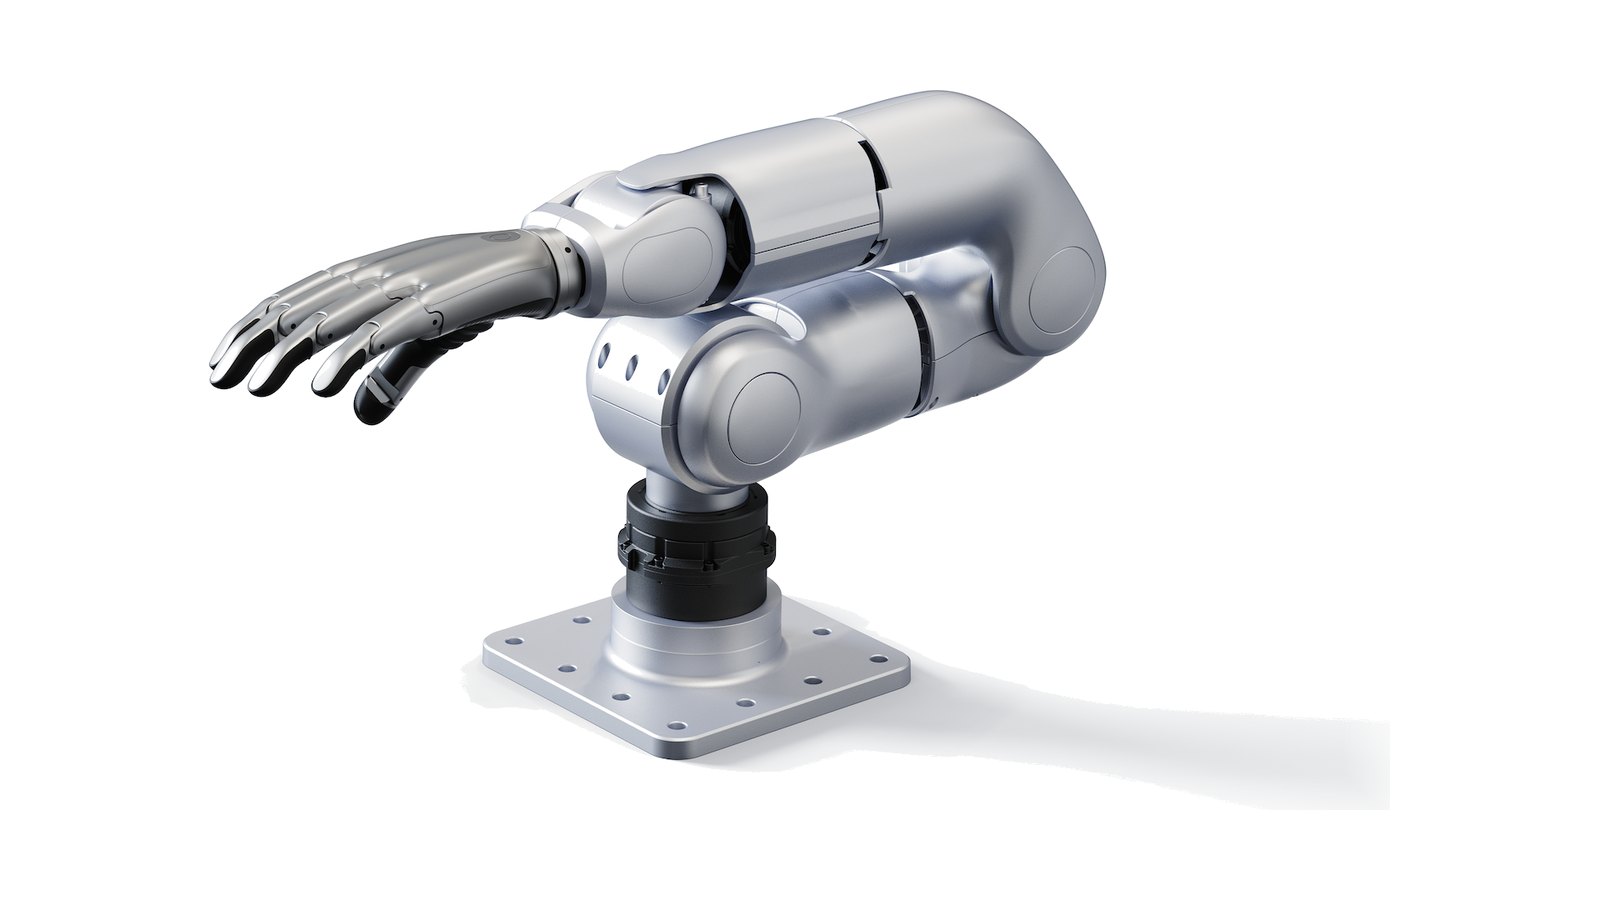
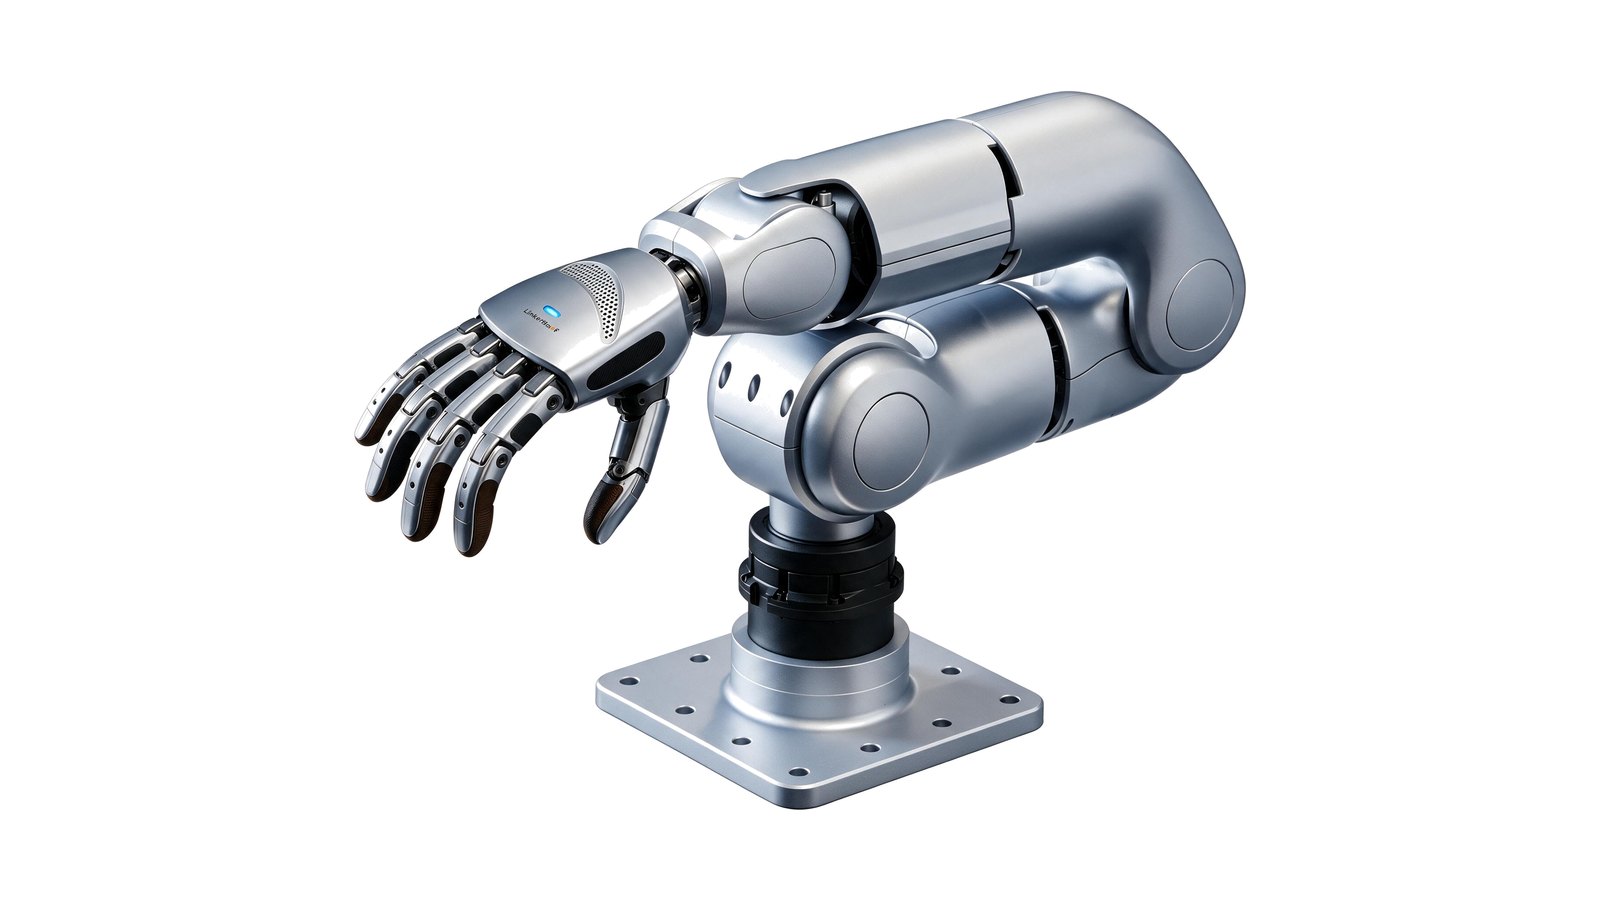
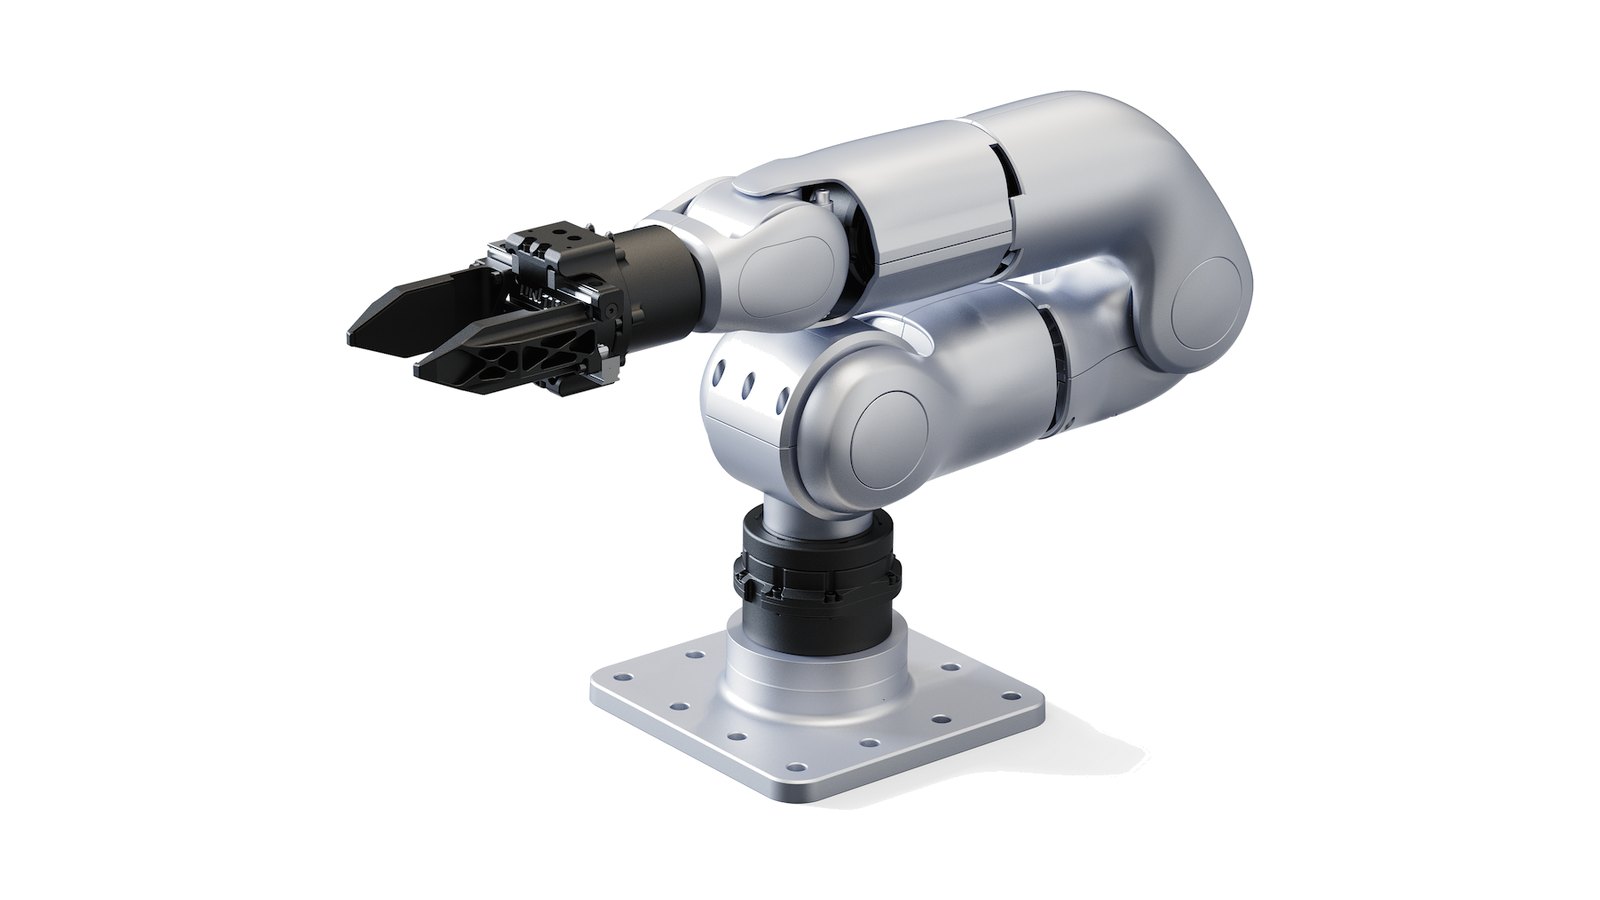
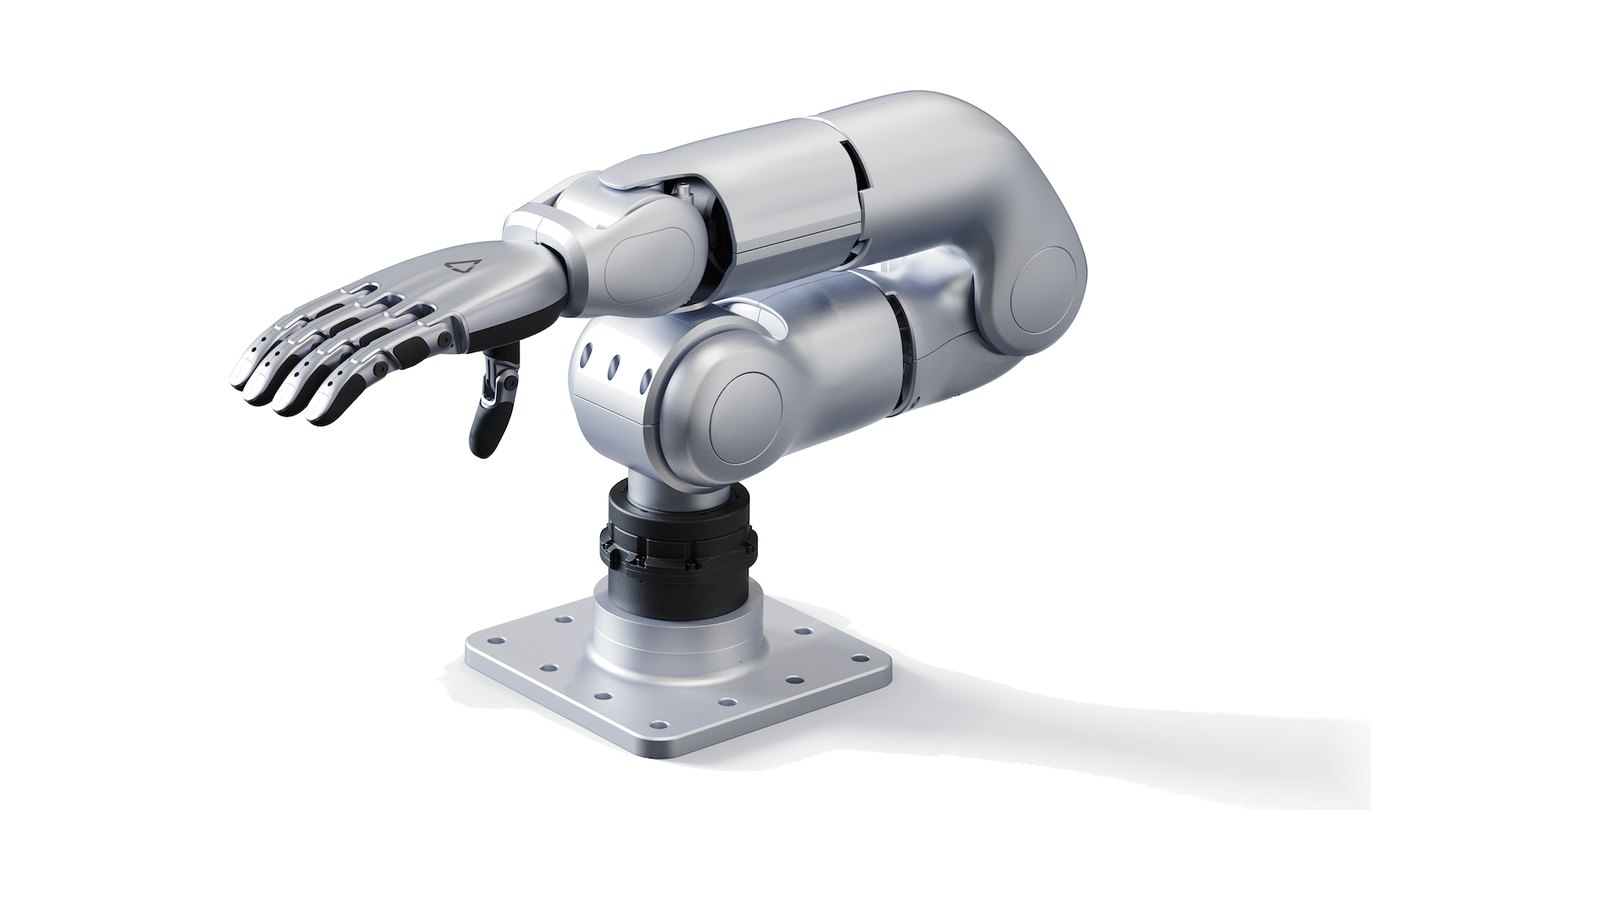
Order the arm on its own or with a factory-fitted end effector: the Dex1-1 parallel gripper (with or without a wrist RGB camera), the Dex3-1 force-controlled three-finger hand, the BrainCo Revo 2 or Linker Hand O6 five-finger hands, each with or without tactile sensing, or the DEX 2/5 tendon-driven hand. Total degrees of freedom run from 7 for the bare arm to 14 with the Dex3-1.
Made to ride on an AS2
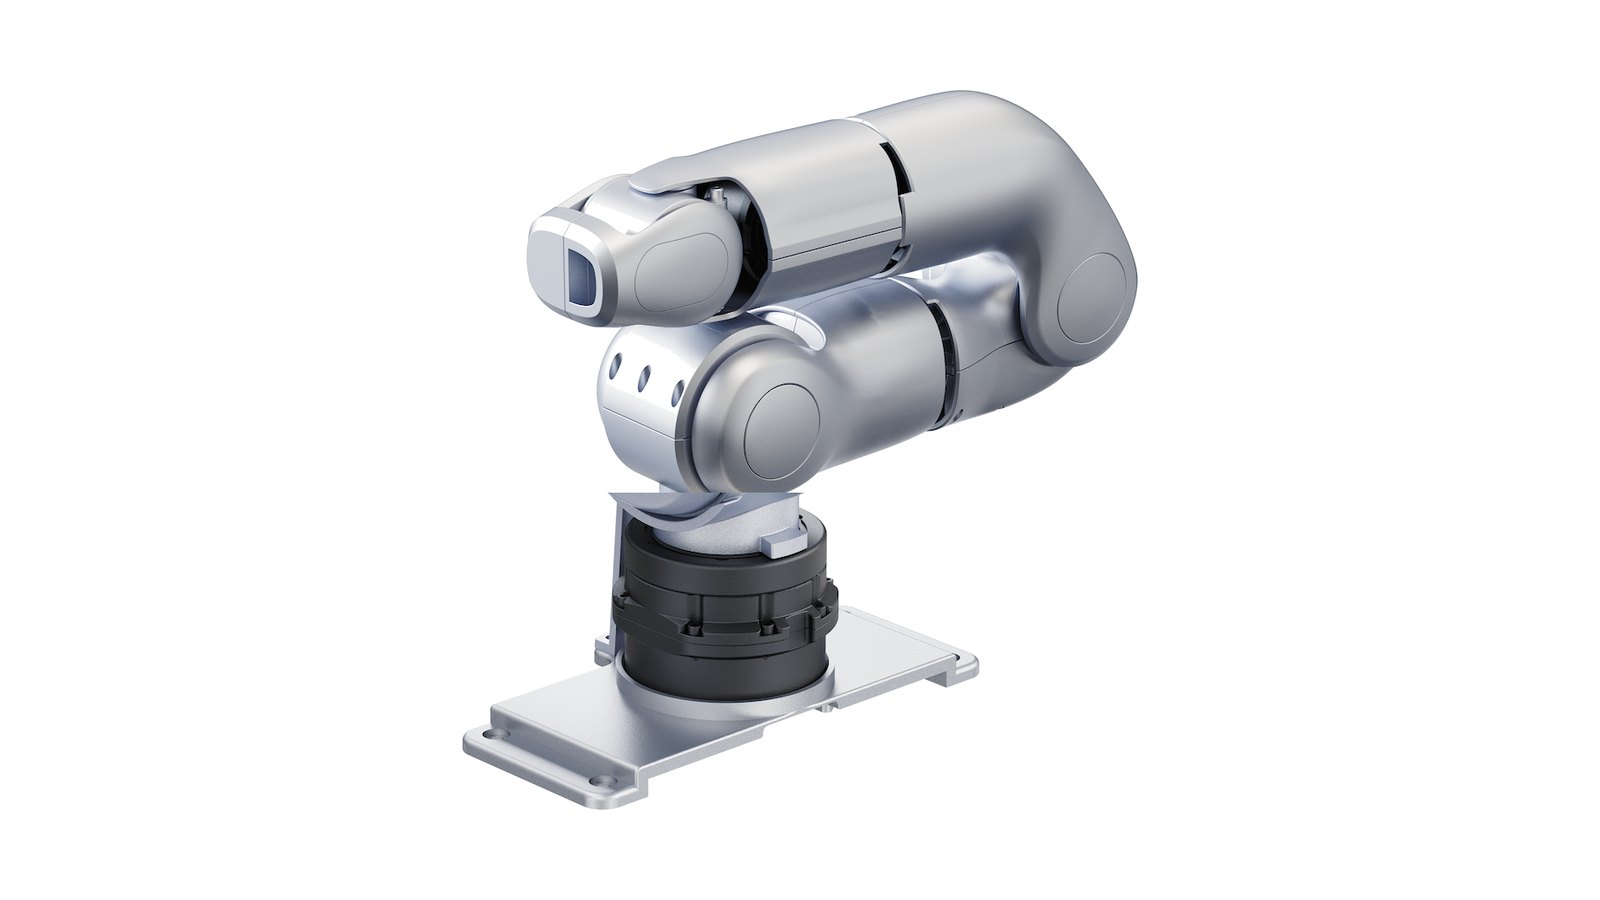
Mobile manipulation, ready to mount.

Made to ride on an AS2

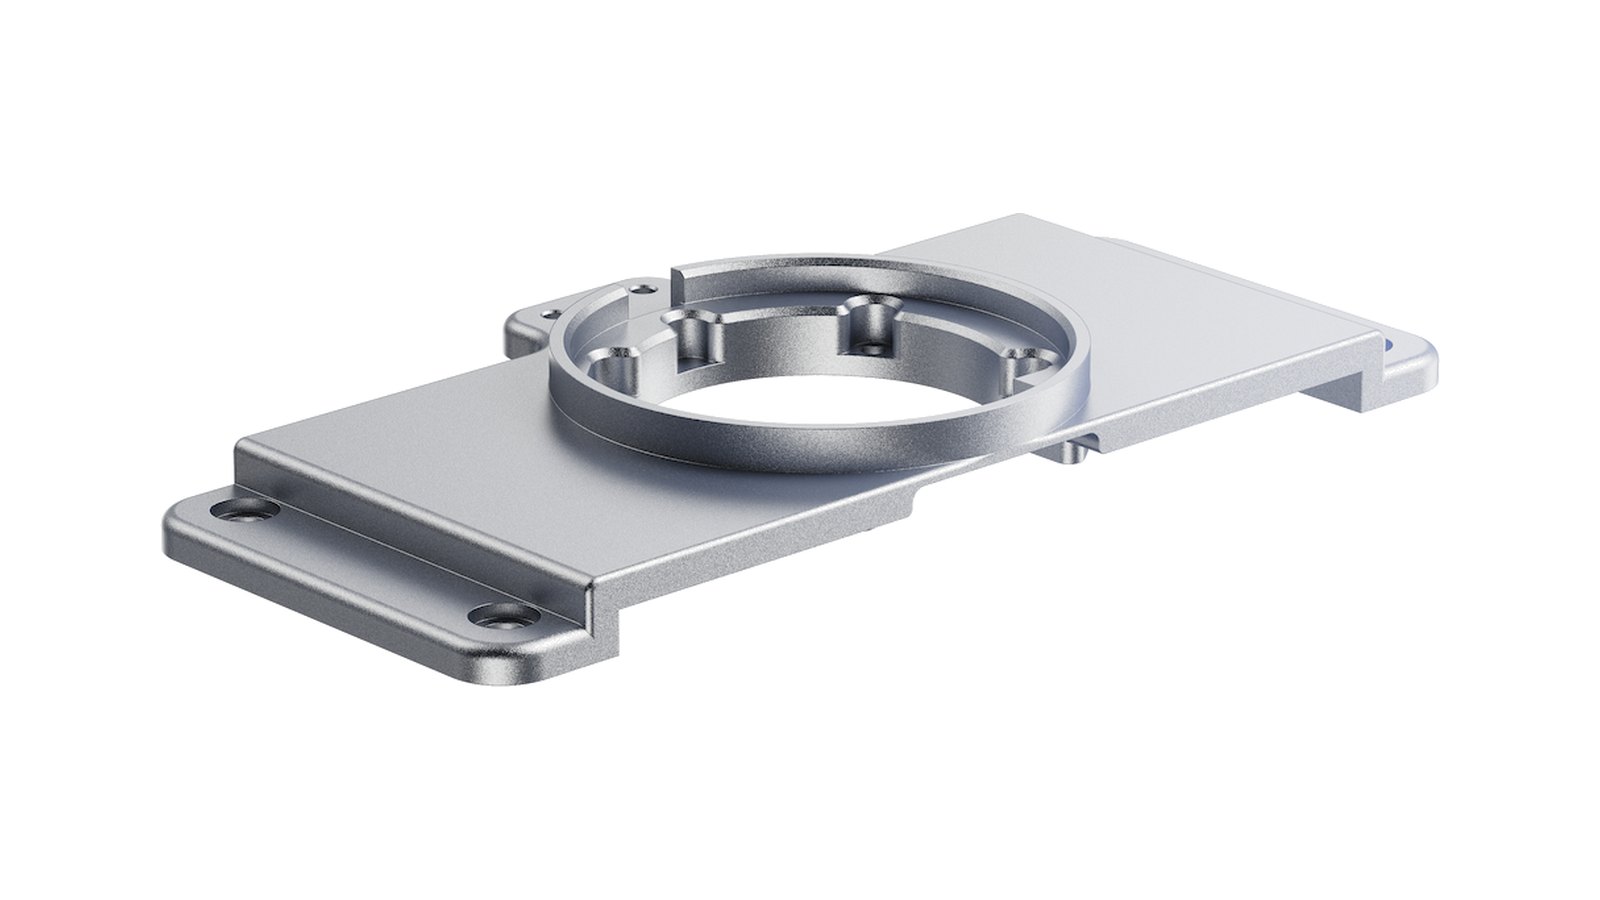
Every build is also offered as an AS2 mount version that ships with the AS2 adapter base, so the arm bolts onto a Unitree AS2 or AS2-W quadruped. The adapter base is also sold on its own for arms already in service.

Performance

Key Specifications

7 Degrees of Freedom
470 mm Reach
~5.5 kg Weight
~60 N.m Joint torque
24 to 60 V Supply
10 Builds
Unitree R1 Robotic Arm — view 1 Unitree R1 Robotic Arm — view 2 Unitree R1 Robotic Arm — view 3 Unitree R1 Robotic Arm — view 4 Unitree R1 Robotic Arm — view 5 Unitree R1 Robotic Arm — view 6
R1 Robotic Arm Parameters

Every build, side by side.

✓ included   ✗ not included
Pick up to 4 to compare
Specification Standard · arm only ★ Professional A · Dex1-1 gripper Professional B · Dex1-1 Plus gripper (RGB) Professional C · Dex3-1 hand Professional D · Dex3-1 tactile hand Professional E · BrainCo Revo 2 hand Professional F · BrainCo Revo 2 tactile hand Professional G · Linker O6 hand Professional H · Linker O6 tactile hand Professional I · DEX 2/5 hand Standard · arm only · AS2 mount Professional A · Dex1-1 gripper · AS2 mount Professional B · Dex1-1 Plus gripper (RGB) · AS2 mount Professional C · Dex3-1 hand · AS2 mount Professional D · Dex3-1 tactile hand · AS2 mount Professional E · BrainCo Revo 2 hand · AS2 mount Professional F · BrainCo Revo 2 tactile hand · AS2 mount Professional G · Linker O6 hand · AS2 mount Professional H · Linker O6 tactile hand · AS2 mount Professional I · DEX 2/5 hand · AS2 mount
Specifications
In the box R1 Robotic Arm, 7-DOF R1 Robotic Arm, 7-DOF, Dex1-1 Standard Gripper x1 R1 Robotic Arm, 7-DOF, Dex1-1 Plus Gripper with wrist RGB camera x1 R1 Robotic Arm, 7-DOF, Dex3-1 three-finger hand (non-tactile) with wrist RGB camera x1 R1 Robotic Arm, 7-DOF, Dex3-1 three-finger hand (tactile) with wrist RGB camera x1 R1 Robotic Arm, 7-DOF, BrainCo Revo 2 Basic hand with wrist RGB camera x1 R1 Robotic Arm, 7-DOF, BrainCo Revo 2 Tactile hand with wrist RGB camera x1 R1 Robotic Arm, 7-DOF, Linker Hand O6 (non-tactile) with wrist RGB camera x1 R1 Robotic Arm, 7-DOF, Linker Hand O6 (tactile) with wrist RGB camera x1 R1 Robotic Arm, 7-DOF, DEX 2/5 tendon-driven hand x1 R1 Robotic Arm, 7-DOF, AS2 adapter base x1 R1 Robotic Arm, 7-DOF, Dex1-1 Standard Gripper x1, AS2 adapter base x1 R1 Robotic Arm, 7-DOF, Dex1-1 Plus Gripper with wrist RGB camera x1, AS2 adapter base x1 R1 Robotic Arm, 7-DOF, Dex3-1 three-finger hand (non-tactile) with wrist RGB camera x1, AS2 adapter base x1 R1 Robotic Arm, 7-DOF, Dex3-1 three-finger hand (tactile) with wrist RGB camera x1, AS2 adapter base x1 R1 Robotic Arm, 7-DOF, BrainCo Revo 2 Basic hand with wrist RGB camera x1, AS2 adapter base x1 R1 Robotic Arm, 7-DOF, BrainCo Revo 2 Tactile hand with wrist RGB camera x1, AS2 adapter base x1 R1 Robotic Arm, 7-DOF, Linker Hand O6 (non-tactile) with wrist RGB camera x1, AS2 adapter base x1 R1 Robotic Arm, 7-DOF, Linker Hand O6 (tactile) with wrist RGB camera x1, AS2 adapter base x1 R1 Robotic Arm, 7-DOF, DEX 2/5 tendon-driven hand x1, AS2 adapter base x1
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid. Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid. Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid. Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid. Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid. Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid. Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid. Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid. Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid. Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid. Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid. Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid. Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid. Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid. Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid. Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid. Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid. Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid. Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid. Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Arm only, no gripper or hand fitted. No RGB camera. Fitted with one Dex1-1 Standard Gripper: 143 x 78 x 67 mm, 550 g, 90 mm stroke, 0.1 mm fingertip resolution, grip force 5 to 120 N adjustable, 20 kg conforming / 5 kg friction grasp load, 0.24 s shortest full-stroke close, 80 mm jaw, high-speed 485. No RGB camera. Fitted with one Dex1-1 Plus Gripper with wrist RGB camera: 143 x 78 x 67 mm, 550 g, 90 mm stroke, 0.1 mm fingertip resolution, grip force 5 to 120 N adjustable, 20 kg conforming / 5 kg friction grasp load, 80 mm jaw, high-speed 485. Fitted with one Dex3-1 force-controlled three-finger dexterous hand, non-tactile, with wrist RGB camera: approx. 650 g, 175 x 88 x 77 mm, 7 DOF per hand (thumb 3, index 2, middle 2), 12 to 58 V, USB. Fitted with one Dex3-1 force-controlled three-finger dexterous hand, tactile, with wrist RGB camera: approx. 650 g, 175 x 88 x 77 mm, 7 DOF per hand, 33 tactile sensors, sensing range 10 g to 2500 g, 12 to 58 V, USB. Fitted with one BrainCo Revo 2 Basic five-finger dexterous hand with wrist RGB camera: 6 DOF, 11 joints, 383 g, 50 N overall grip, 15 N single-finger pinch, 0.1 degree repeat accuracy, 160 mm tall. Fitted with one BrainCo Revo 2 Tactile five-finger dexterous hand with wrist RGB camera: 6 DOF, 11 joints, 383 g, 50 N overall grip, 15 N single-finger pinch, built-in tactile sensing for pressure, friction, direction and proximity. Fitted with one Linker Hand O6, non-tactile, with wrist RGB camera: 6 DOF, 11 joints (6 active, 5 passive), 370 g, 50 kg max load, linkage drive, repeat positioning better than 0.20 mm, thumb fingertip force 20 N, four-finger 25 N, five-finger grip 70 N. Fitted with one Linker Hand O6, tactile, with wrist RGB camera: 6 DOF, 11 joints (6 active, 5 passive), 370 g, 50 kg max load, linkage drive, repeat positioning better than 0.20 mm, thumb fingertip force 20 N, four-finger 25 N, five-finger grip 70 N, built-in tactile sensing. Fitted with one DEX 2/5 tendon-driven dexterous hand: 2 DOF, 10 joints, approx. 151 x 67 x 70 mm, 365 g, 24 to 58 V, 10 N fingertip force, no tactile sensing. No external cabling between hand and body. No wrist camera. Arm only, no gripper or hand fitted. No RGB camera. Fitted with one Dex1-1 Standard Gripper: 143 x 78 x 67 mm, 550 g, 90 mm stroke, 0.1 mm fingertip resolution, grip force 5 to 120 N adjustable, 20 kg conforming / 5 kg friction grasp load, 0.24 s shortest full-stroke close, 80 mm jaw, high-speed 485. No RGB camera. Fitted with one Dex1-1 Plus Gripper with wrist RGB camera: 143 x 78 x 67 mm, 550 g, 90 mm stroke, 0.1 mm fingertip resolution, grip force 5 to 120 N adjustable, 20 kg conforming / 5 kg friction grasp load, 80 mm jaw, high-speed 485. Fitted with one Dex3-1 force-controlled three-finger dexterous hand, non-tactile, with wrist RGB camera: approx. 650 g, 175 x 88 x 77 mm, 7 DOF per hand (thumb 3, index 2, middle 2), 12 to 58 V, USB. Fitted with one Dex3-1 force-controlled three-finger dexterous hand, tactile, with wrist RGB camera: approx. 650 g, 175 x 88 x 77 mm, 7 DOF per hand, 33 tactile sensors, sensing range 10 g to 2500 g, 12 to 58 V, USB. Fitted with one BrainCo Revo 2 Basic five-finger dexterous hand with wrist RGB camera: 6 DOF, 11 joints, 383 g, 50 N overall grip, 15 N single-finger pinch, 0.1 degree repeat accuracy, 160 mm tall. Fitted with one BrainCo Revo 2 Tactile five-finger dexterous hand with wrist RGB camera: 6 DOF, 11 joints, 383 g, 50 N overall grip, 15 N single-finger pinch, built-in tactile sensing for pressure, friction, direction and proximity. Fitted with one Linker Hand O6, non-tactile, with wrist RGB camera: 6 DOF, 11 joints (6 active, 5 passive), 370 g, 50 kg max load, linkage drive, repeat positioning better than 0.20 mm, thumb fingertip force 20 N, four-finger 25 N, five-finger grip 70 N. Fitted with one Linker Hand O6, tactile, with wrist RGB camera: 6 DOF, 11 joints (6 active, 5 passive), 370 g, 50 kg max load, linkage drive, repeat positioning better than 0.20 mm, thumb fingertip force 20 N, four-finger 25 N, five-finger grip 70 N, built-in tactile sensing. Fitted with one DEX 2/5 tendon-driven dexterous hand: 2 DOF, 10 joints, approx. 151 x 67 x 70 mm, 365 g, 24 to 58 V, 10 N fingertip force, no tactile sensing. No external cabling between hand and body. No wrist camera.
Total DOF 7 8 (arm 7 + gripper 1) 8 (arm 7 + gripper 1) 14 (arm 7 + hand 7) 14 (arm 7 + hand 7) 13 (arm 7 + hand 6) 13 (arm 7 + hand 6) 13 (arm 7 + hand 6) 13 (arm 7 + hand 6) 9 (arm 7 + hand 2) 7 8 (arm 7 + gripper 1) 8 (arm 7 + gripper 1) 14 (arm 7 + hand 7) 14 (arm 7 + hand 7) 13 (arm 7 + hand 6) 13 (arm 7 + hand 6) 13 (arm 7 + hand 6) 13 (arm 7 + hand 6) 9 (arm 7 + hand 2)
Mount Flat base plate Flat base plate Flat base plate Flat base plate Flat base plate Flat base plate Flat base plate Flat base plate Flat base plate Flat base plate AS2 adapter base, for AS2 and AS2-W quadrupeds AS2 adapter base, for AS2 and AS2-W quadrupeds AS2 adapter base, for AS2 and AS2-W quadrupeds AS2 adapter base, for AS2 and AS2-W quadrupeds AS2 adapter base, for AS2 and AS2-W quadrupeds AS2 adapter base, for AS2 and AS2-W quadrupeds AS2 adapter base, for AS2 and AS2-W quadrupeds AS2 adapter base, for AS2 and AS2-W quadrupeds AS2 adapter base, for AS2 and AS2-W quadrupeds AS2 adapter base, for AS2 and AS2-W quadrupeds
Wrist camera No No Yes, RGB Yes, RGB Yes, RGB Yes, RGB Yes, RGB Yes, RGB Yes, RGB No No No Yes, RGB Yes, RGB Yes, RGB Yes, RGB Yes, RGB Yes, RGB Yes, RGB No
Reach 470 mm (650 mm working radius with a hand fitted) 470 mm (650 mm working radius with a hand fitted) 470 mm (650 mm working radius with a hand fitted) 470 mm (650 mm working radius with a hand fitted) 470 mm (650 mm working radius with a hand fitted) 470 mm (650 mm working radius with a hand fitted) 470 mm (650 mm working radius with a hand fitted) 470 mm (650 mm working radius with a hand fitted) 470 mm (650 mm working radius with a hand fitted) 470 mm (650 mm working radius with a hand fitted) 470 mm (650 mm working radius with a hand fitted) 470 mm (650 mm working radius with a hand fitted) 470 mm (650 mm working radius with a hand fitted) 470 mm (650 mm working radius with a hand fitted) 470 mm (650 mm working radius with a hand fitted) 470 mm (650 mm working radius with a hand fitted) 470 mm (650 mm working radius with a hand fitted) 470 mm (650 mm working radius with a hand fitted) 470 mm (650 mm working radius with a hand fitted) 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg Approx. 5.5 kg Approx. 5.5 kg Approx. 5.5 kg Approx. 5.5 kg Approx. 5.5 kg Approx. 5.5 kg Approx. 5.5 kg Approx. 5.5 kg Approx. 5.5 kg Approx. 5.5 kg Approx. 5.5 kg Approx. 5.5 kg Approx. 5.5 kg Approx. 5.5 kg Approx. 5.5 kg Approx. 5.5 kg Approx. 5.5 kg Approx. 5.5 kg Approx. 5.5 kg
Max joint torque Approx. 60 N.m Approx. 60 N.m Approx. 60 N.m Approx. 60 N.m Approx. 60 N.m Approx. 60 N.m Approx. 60 N.m Approx. 60 N.m Approx. 60 N.m Approx. 60 N.m Approx. 60 N.m Approx. 60 N.m Approx. 60 N.m Approx. 60 N.m Approx. 60 N.m Approx. 60 N.m Approx. 60 N.m Approx. 60 N.m Approx. 60 N.m Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak 24 to 60 V, typical 50 W or less, 700 W peak 24 to 60 V, typical 50 W or less, 700 W peak 24 to 60 V, typical 50 W or less, 700 W peak 24 to 60 V, typical 50 W or less, 700 W peak 24 to 60 V, typical 50 W or less, 700 W peak 24 to 60 V, typical 50 W or less, 700 W peak 24 to 60 V, typical 50 W or less, 700 W peak 24 to 60 V, typical 50 W or less, 700 W peak 24 to 60 V, typical 50 W or less, 700 W peak 24 to 60 V, typical 50 W or less, 700 W peak 24 to 60 V, typical 50 W or less, 700 W peak 24 to 60 V, typical 50 W or less, 700 W peak 24 to 60 V, typical 50 W or less, 700 W peak 24 to 60 V, typical 50 W or less, 700 W peak 24 to 60 V, typical 50 W or less, 700 W peak 24 to 60 V, typical 50 W or less, 700 W peak 24 to 60 V, typical 50 W or less, 700 W peak 24 to 60 V, typical 50 W or less, 700 W peak 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image) Right arm by default, left arm on request (mirror image) Right arm by default, left arm on request (mirror image) Right arm by default, left arm on request (mirror image) Right arm by default, left arm on request (mirror image) Right arm by default, left arm on request (mirror image) Right arm by default, left arm on request (mirror image) Right arm by default, left arm on request (mirror image) Right arm by default, left arm on request (mirror image) Right arm by default, left arm on request (mirror image) Right arm by default, left arm on request (mirror image) Right arm by default, left arm on request (mirror image) Right arm by default, left arm on request (mirror image) Right arm by default, left arm on request (mirror image) Right arm by default, left arm on request (mirror image) Right arm by default, left arm on request (mirror image) Right arm by default, left arm on request (mirror image) Right arm by default, left arm on request (mirror image) Right arm by default, left arm on request (mirror image) Right arm by default, left arm on request (mirror image)
Warranty 12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months12 months
Price ex VAT R 28,875 R 34,125 R 36,750 R 116,375 R 133,875 R 92,750 R 127,750 R 49,000 R 51,625 R 48,125 R 30,187.50 R 35,437.50 R 38,062.50 R 117,687.50 R 135,187.50 R 94,062.50 R 129,062.50 R 50,312.50 R 52,937.50 R 49,437.50
Standard · arm only ★ R 28,875
Specifications
In the box R1 Robotic Arm, 7-DOF
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Arm only, no gripper or hand fitted. No RGB camera.
Total DOF 7
Mount Flat base plate
Wrist camera No
Reach 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg
Max joint torque Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image)
Warranty12 months
Configure this build
Professional A · Dex1-1 gripper R 34,125
Specifications
In the box R1 Robotic Arm, 7-DOF, Dex1-1 Standard Gripper x1
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Fitted with one Dex1-1 Standard Gripper: 143 x 78 x 67 mm, 550 g, 90 mm stroke, 0.1 mm fingertip resolution, grip force 5 to 120 N adjustable, 20 kg conforming / 5 kg friction grasp load, 0.24 s shortest full-stroke close, 80 mm jaw, high-speed 485. No RGB camera.
Total DOF 8 (arm 7 + gripper 1)
Mount Flat base plate
Wrist camera No
Reach 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg
Max joint torque Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image)
Warranty12 months
Configure this build
Professional B · Dex1-1 Plus gripper (RGB) R 36,750
Specifications
In the box R1 Robotic Arm, 7-DOF, Dex1-1 Plus Gripper with wrist RGB camera x1
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Fitted with one Dex1-1 Plus Gripper with wrist RGB camera: 143 x 78 x 67 mm, 550 g, 90 mm stroke, 0.1 mm fingertip resolution, grip force 5 to 120 N adjustable, 20 kg conforming / 5 kg friction grasp load, 80 mm jaw, high-speed 485.
Total DOF 8 (arm 7 + gripper 1)
Mount Flat base plate
Wrist camera Yes, RGB
Reach 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg
Max joint torque Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image)
Warranty12 months
Configure this build
Professional C · Dex3-1 hand R 116,375
Specifications
In the box R1 Robotic Arm, 7-DOF, Dex3-1 three-finger hand (non-tactile) with wrist RGB camera x1
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Fitted with one Dex3-1 force-controlled three-finger dexterous hand, non-tactile, with wrist RGB camera: approx. 650 g, 175 x 88 x 77 mm, 7 DOF per hand (thumb 3, index 2, middle 2), 12 to 58 V, USB.
Total DOF 14 (arm 7 + hand 7)
Mount Flat base plate
Wrist camera Yes, RGB
Reach 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg
Max joint torque Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image)
Warranty12 months
Configure this build
Professional D · Dex3-1 tactile hand R 133,875
Specifications
In the box R1 Robotic Arm, 7-DOF, Dex3-1 three-finger hand (tactile) with wrist RGB camera x1
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Fitted with one Dex3-1 force-controlled three-finger dexterous hand, tactile, with wrist RGB camera: approx. 650 g, 175 x 88 x 77 mm, 7 DOF per hand, 33 tactile sensors, sensing range 10 g to 2500 g, 12 to 58 V, USB.
Total DOF 14 (arm 7 + hand 7)
Mount Flat base plate
Wrist camera Yes, RGB
Reach 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg
Max joint torque Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image)
Warranty12 months
Configure this build
Professional E · BrainCo Revo 2 hand R 92,750
Specifications
In the box R1 Robotic Arm, 7-DOF, BrainCo Revo 2 Basic hand with wrist RGB camera x1
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Fitted with one BrainCo Revo 2 Basic five-finger dexterous hand with wrist RGB camera: 6 DOF, 11 joints, 383 g, 50 N overall grip, 15 N single-finger pinch, 0.1 degree repeat accuracy, 160 mm tall.
Total DOF 13 (arm 7 + hand 6)
Mount Flat base plate
Wrist camera Yes, RGB
Reach 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg
Max joint torque Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image)
Warranty12 months
Configure this build
Professional F · BrainCo Revo 2 tactile hand R 127,750
Specifications
In the box R1 Robotic Arm, 7-DOF, BrainCo Revo 2 Tactile hand with wrist RGB camera x1
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Fitted with one BrainCo Revo 2 Tactile five-finger dexterous hand with wrist RGB camera: 6 DOF, 11 joints, 383 g, 50 N overall grip, 15 N single-finger pinch, built-in tactile sensing for pressure, friction, direction and proximity.
Total DOF 13 (arm 7 + hand 6)
Mount Flat base plate
Wrist camera Yes, RGB
Reach 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg
Max joint torque Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image)
Warranty12 months
Configure this build
Professional G · Linker O6 hand R 49,000
Specifications
In the box R1 Robotic Arm, 7-DOF, Linker Hand O6 (non-tactile) with wrist RGB camera x1
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Fitted with one Linker Hand O6, non-tactile, with wrist RGB camera: 6 DOF, 11 joints (6 active, 5 passive), 370 g, 50 kg max load, linkage drive, repeat positioning better than 0.20 mm, thumb fingertip force 20 N, four-finger 25 N, five-finger grip 70 N.
Total DOF 13 (arm 7 + hand 6)
Mount Flat base plate
Wrist camera Yes, RGB
Reach 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg
Max joint torque Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image)
Warranty12 months
Configure this build
Professional H · Linker O6 tactile hand R 51,625
Specifications
In the box R1 Robotic Arm, 7-DOF, Linker Hand O6 (tactile) with wrist RGB camera x1
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Fitted with one Linker Hand O6, tactile, with wrist RGB camera: 6 DOF, 11 joints (6 active, 5 passive), 370 g, 50 kg max load, linkage drive, repeat positioning better than 0.20 mm, thumb fingertip force 20 N, four-finger 25 N, five-finger grip 70 N, built-in tactile sensing.
Total DOF 13 (arm 7 + hand 6)
Mount Flat base plate
Wrist camera Yes, RGB
Reach 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg
Max joint torque Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image)
Warranty12 months
Configure this build
Professional I · DEX 2/5 hand R 48,125
Specifications
In the box R1 Robotic Arm, 7-DOF, DEX 2/5 tendon-driven hand x1
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Fitted with one DEX 2/5 tendon-driven dexterous hand: 2 DOF, 10 joints, approx. 151 x 67 x 70 mm, 365 g, 24 to 58 V, 10 N fingertip force, no tactile sensing. No external cabling between hand and body. No wrist camera.
Total DOF 9 (arm 7 + hand 2)
Mount Flat base plate
Wrist camera No
Reach 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg
Max joint torque Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image)
Warranty12 months
Configure this build
Standard · arm only · AS2 mount R 30,187.50
Specifications
In the box R1 Robotic Arm, 7-DOF, AS2 adapter base x1
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Arm only, no gripper or hand fitted. No RGB camera.
Total DOF 7
Mount AS2 adapter base, for AS2 and AS2-W quadrupeds
Wrist camera No
Reach 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg
Max joint torque Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image)
Warranty12 months
Configure this build
Professional A · Dex1-1 gripper · AS2 mount R 35,437.50
Specifications
In the box R1 Robotic Arm, 7-DOF, Dex1-1 Standard Gripper x1, AS2 adapter base x1
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Fitted with one Dex1-1 Standard Gripper: 143 x 78 x 67 mm, 550 g, 90 mm stroke, 0.1 mm fingertip resolution, grip force 5 to 120 N adjustable, 20 kg conforming / 5 kg friction grasp load, 0.24 s shortest full-stroke close, 80 mm jaw, high-speed 485. No RGB camera.
Total DOF 8 (arm 7 + gripper 1)
Mount AS2 adapter base, for AS2 and AS2-W quadrupeds
Wrist camera No
Reach 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg
Max joint torque Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image)
Warranty12 months
Configure this build
Professional B · Dex1-1 Plus gripper (RGB) · AS2 mount R 38,062.50
Specifications
In the box R1 Robotic Arm, 7-DOF, Dex1-1 Plus Gripper with wrist RGB camera x1, AS2 adapter base x1
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Fitted with one Dex1-1 Plus Gripper with wrist RGB camera: 143 x 78 x 67 mm, 550 g, 90 mm stroke, 0.1 mm fingertip resolution, grip force 5 to 120 N adjustable, 20 kg conforming / 5 kg friction grasp load, 80 mm jaw, high-speed 485.
Total DOF 8 (arm 7 + gripper 1)
Mount AS2 adapter base, for AS2 and AS2-W quadrupeds
Wrist camera Yes, RGB
Reach 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg
Max joint torque Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image)
Warranty12 months
Configure this build
Professional C · Dex3-1 hand · AS2 mount R 117,687.50
Specifications
In the box R1 Robotic Arm, 7-DOF, Dex3-1 three-finger hand (non-tactile) with wrist RGB camera x1, AS2 adapter base x1
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Fitted with one Dex3-1 force-controlled three-finger dexterous hand, non-tactile, with wrist RGB camera: approx. 650 g, 175 x 88 x 77 mm, 7 DOF per hand (thumb 3, index 2, middle 2), 12 to 58 V, USB.
Total DOF 14 (arm 7 + hand 7)
Mount AS2 adapter base, for AS2 and AS2-W quadrupeds
Wrist camera Yes, RGB
Reach 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg
Max joint torque Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image)
Warranty12 months
Configure this build
Professional D · Dex3-1 tactile hand · AS2 mount R 135,187.50
Specifications
In the box R1 Robotic Arm, 7-DOF, Dex3-1 three-finger hand (tactile) with wrist RGB camera x1, AS2 adapter base x1
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Fitted with one Dex3-1 force-controlled three-finger dexterous hand, tactile, with wrist RGB camera: approx. 650 g, 175 x 88 x 77 mm, 7 DOF per hand, 33 tactile sensors, sensing range 10 g to 2500 g, 12 to 58 V, USB.
Total DOF 14 (arm 7 + hand 7)
Mount AS2 adapter base, for AS2 and AS2-W quadrupeds
Wrist camera Yes, RGB
Reach 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg
Max joint torque Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image)
Warranty12 months
Configure this build
Professional E · BrainCo Revo 2 hand · AS2 mount R 94,062.50
Specifications
In the box R1 Robotic Arm, 7-DOF, BrainCo Revo 2 Basic hand with wrist RGB camera x1, AS2 adapter base x1
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Fitted with one BrainCo Revo 2 Basic five-finger dexterous hand with wrist RGB camera: 6 DOF, 11 joints, 383 g, 50 N overall grip, 15 N single-finger pinch, 0.1 degree repeat accuracy, 160 mm tall.
Total DOF 13 (arm 7 + hand 6)
Mount AS2 adapter base, for AS2 and AS2-W quadrupeds
Wrist camera Yes, RGB
Reach 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg
Max joint torque Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image)
Warranty12 months
Configure this build
Professional F · BrainCo Revo 2 tactile hand · AS2 mount R 129,062.50
Specifications
In the box R1 Robotic Arm, 7-DOF, BrainCo Revo 2 Tactile hand with wrist RGB camera x1, AS2 adapter base x1
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Fitted with one BrainCo Revo 2 Tactile five-finger dexterous hand with wrist RGB camera: 6 DOF, 11 joints, 383 g, 50 N overall grip, 15 N single-finger pinch, built-in tactile sensing for pressure, friction, direction and proximity.
Total DOF 13 (arm 7 + hand 6)
Mount AS2 adapter base, for AS2 and AS2-W quadrupeds
Wrist camera Yes, RGB
Reach 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg
Max joint torque Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image)
Warranty12 months
Configure this build
Professional G · Linker O6 hand · AS2 mount R 50,312.50
Specifications
In the box R1 Robotic Arm, 7-DOF, Linker Hand O6 (non-tactile) with wrist RGB camera x1, AS2 adapter base x1
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Fitted with one Linker Hand O6, non-tactile, with wrist RGB camera: 6 DOF, 11 joints (6 active, 5 passive), 370 g, 50 kg max load, linkage drive, repeat positioning better than 0.20 mm, thumb fingertip force 20 N, four-finger 25 N, five-finger grip 70 N.
Total DOF 13 (arm 7 + hand 6)
Mount AS2 adapter base, for AS2 and AS2-W quadrupeds
Wrist camera Yes, RGB
Reach 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg
Max joint torque Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image)
Warranty12 months
Configure this build
Professional H · Linker O6 tactile hand · AS2 mount R 52,937.50
Specifications
In the box R1 Robotic Arm, 7-DOF, Linker Hand O6 (tactile) with wrist RGB camera x1, AS2 adapter base x1
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Fitted with one Linker Hand O6, tactile, with wrist RGB camera: 6 DOF, 11 joints (6 active, 5 passive), 370 g, 50 kg max load, linkage drive, repeat positioning better than 0.20 mm, thumb fingertip force 20 N, four-finger 25 N, five-finger grip 70 N, built-in tactile sensing.
Total DOF 13 (arm 7 + hand 6)
Mount AS2 adapter base, for AS2 and AS2-W quadrupeds
Wrist camera Yes, RGB
Reach 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg
Max joint torque Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image)
Warranty12 months
Configure this build
Professional I · DEX 2/5 hand · AS2 mount R 49,437.50
Specifications
In the box R1 Robotic Arm, 7-DOF, DEX 2/5 tendon-driven hand x1, AS2 adapter base x1
Product type Standalone robotic arm in the Z1 class. Not a replacement arm for the R1 humanoid.
End effector Fitted with one DEX 2/5 tendon-driven dexterous hand: 2 DOF, 10 joints, approx. 151 x 67 x 70 mm, 365 g, 24 to 58 V, 10 N fingertip force, no tactile sensing. No external cabling between hand and body. No wrist camera.
Total DOF 9 (arm 7 + hand 2)
Mount AS2 adapter base, for AS2 and AS2-W quadrupeds
Wrist camera No
Reach 470 mm (650 mm working radius with a hand fitted)
Arm weight Approx. 5.5 kg
Max joint torque Approx. 60 N.m
Supply 24 to 60 V, typical 50 W or less, 700 W peak
Handedness Right arm by default, left arm on request (mirror image)
Warranty12 months
Configure this build

Specifications follow Unitree factory data and may change with firmware and hardware revisions. Rand prices track our live USD exchange rate and exclude VAT, airfreight, customs and delivery, itemised at checkout. ★ default configuration.

Configure & Order

Build your R1 Robotic Arm.

1 — Configuration
2 — Add accessories

TIP: we recommend a second battery with every robot, so one pack charges while the other works.
Questions

R1 Robotic Arm in South Africa — the practical answers.

Pricing starts at R 28,875 ex VAT across 20 configurations. Prices are calculated from Unitree's USD list price at our current exchange rate, so you always see a live Rand price with no hidden markup.
We handle airfreight from the factory, customs clearance and insured local delivery to anywhere in South Africa. These landed costs are itemised on your order before you pay. Typical lead time is 4 to 6 weeks from payment confirmation.
Yes — 12 months depending on configuration, backed by Unitree and handled locally by MCM Robotics as the official South African distributor. Repairs, genuine parts and firmware support run through us.
Add your build to the cart and request a quote: a PDF quotation with our FNB banking details arrives by email within a minute. Orders confirm on EFT receipt, and we support institutional and tender paperwork.
EDU and developer configurations expose Unitree's full SDK: low-level joint control, perception streams and simulation environments (ROS2, Isaac Sim, MuJoCo). See the Education page for curriculum support and tier guidance.
Accessories

Extend the R1 Robotic Arm.

All accessories →
Unitree AS2 Adapter Base Kit
R1 Arm Extras Unitree AS2 Adapter Base Kit R 1,312.50