Specifications
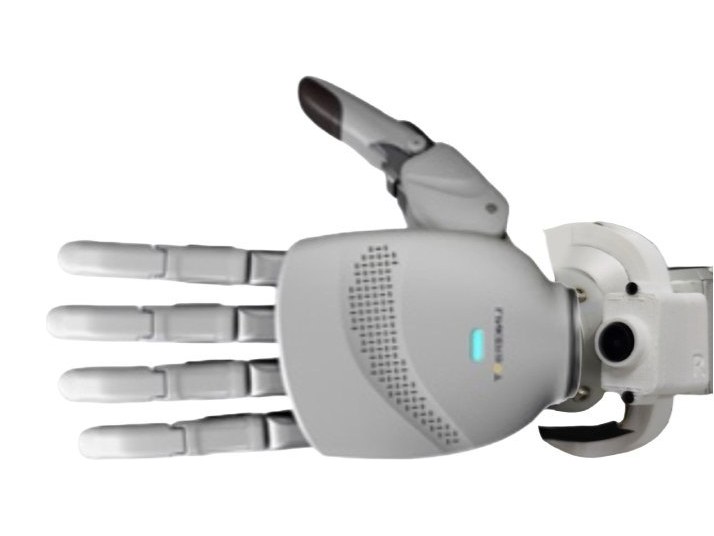
| DOF | 6 (11 joints: 6 active, 5 passive) |
| Weight | 370 g, 50 kg max load |
| Transmission | Linkage drive |
| Tactile sensing | Built in |
| Repeat positioning accuracy | Within ±0.20 mm |
| Fingertip force | Thumb 20 N, four fingers 25 N |
| Grip force | 70 N max (five fingers) |
| Wrist camera | RGB, 1920×1080, FOV D 130°, H 120°, V 81° |
| In the box | Hand, wrist RGB camera, camera bracket, cables and accessories |
| Fits | AS2, R1, R1-A and R1 Arm |