Specifications
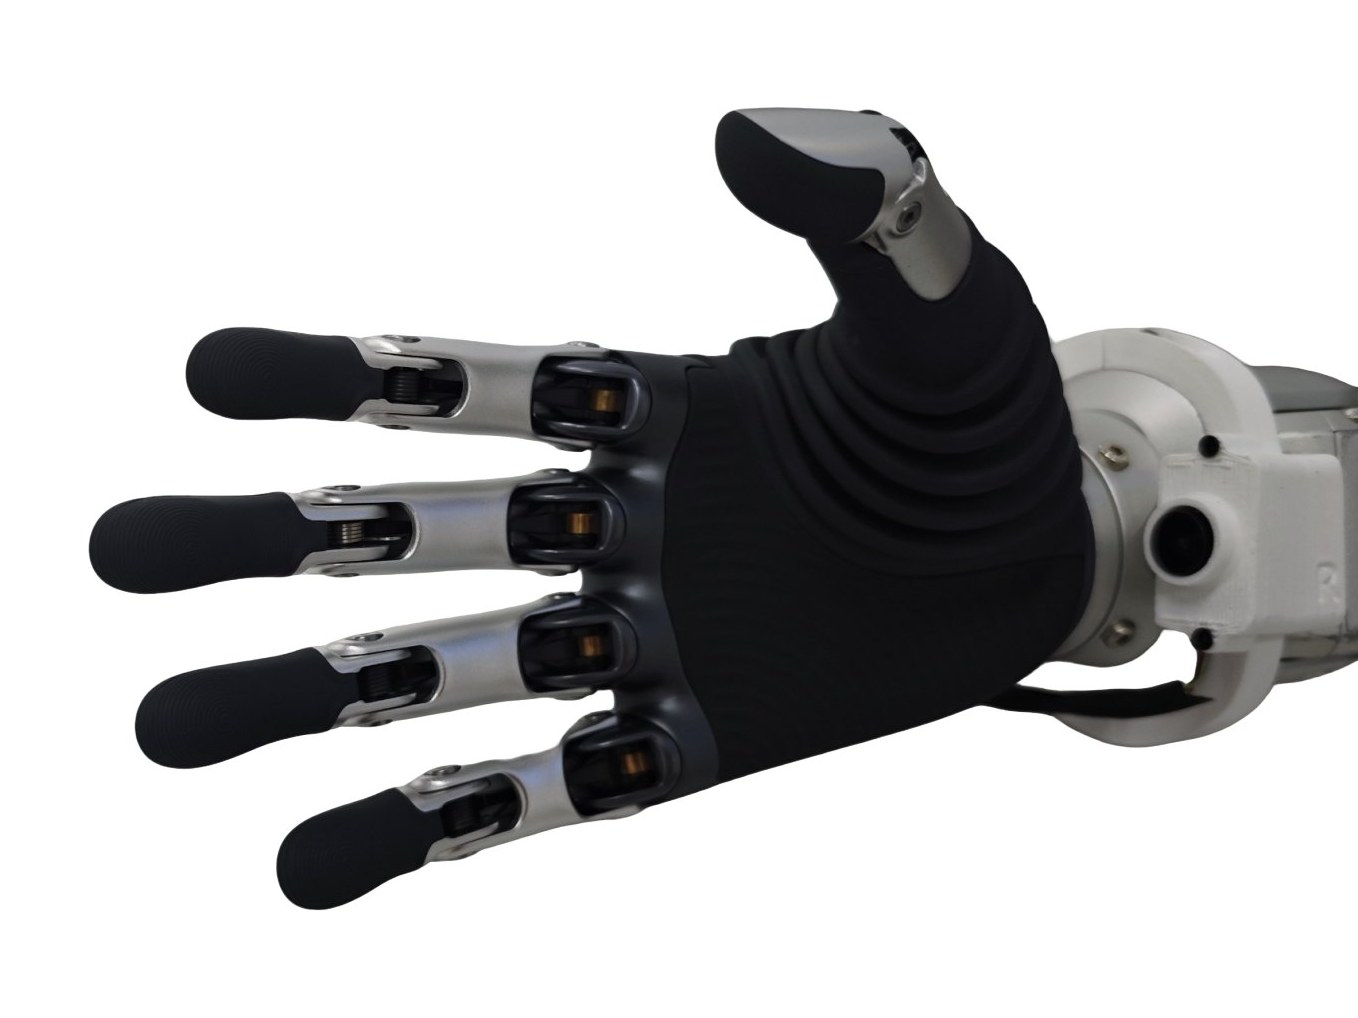
| DOF | 6 active, 11 joints |
| Weight | 383 g |
| Grip force | 50 N overall, 15 N single-finger pinch |
| Repeat accuracy | 0.1° |
| Height | 160 mm (middle fingertip to palm root) |
| Tactile sensing | Pressure, friction, direction, proximity |
| Wrist camera | RGB, 1920x1080, FOV D130° H120° V81° |
| In the box | 1 hand, wrist RGB camera, camera bracket, cables |
| Ordering | Per hand, specify left or right (usually 2 per robot) |
| Availability | Optional on H2-X EDU builds |