Specifications
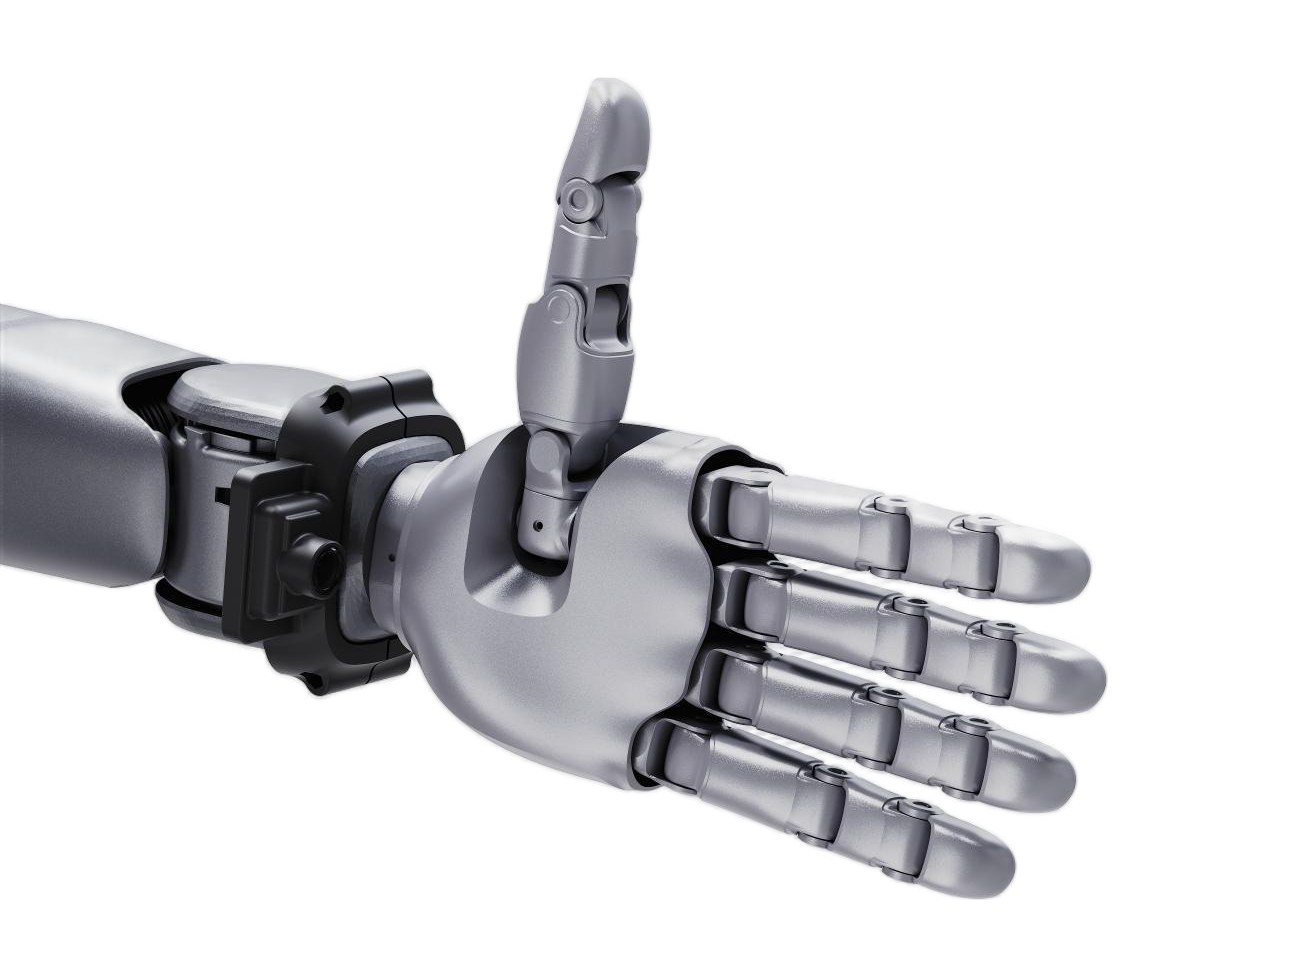
| DOF | 21 active (4 per finger, 5 thumb), direct-drive, backdrivable |
| Dimensions | 215 x 105 x 50 mm |
| Grip force | 70 N active grip, 20 N fingertip pinch |
| Load | 20 kg whole hand, 5 kg four fingers |
| Grasp diameter | 10 to 150 mm |
| Motion | 0.1° repeat accuracy, 3 Hz open/close |
| Power | 12 to 80 V, max 10 A (24 V) |
| Tactile sensing | Full-palm array plus fingertip visual-tactile; 0 to 25 N, 0.01 N, 130 μm min deformation |
| Wrist camera | RGB, 1920x1080, FOV D130° H120° V81° |
| Ordering | Per hand, specify left or right (usually 2 per robot) |