Specifications
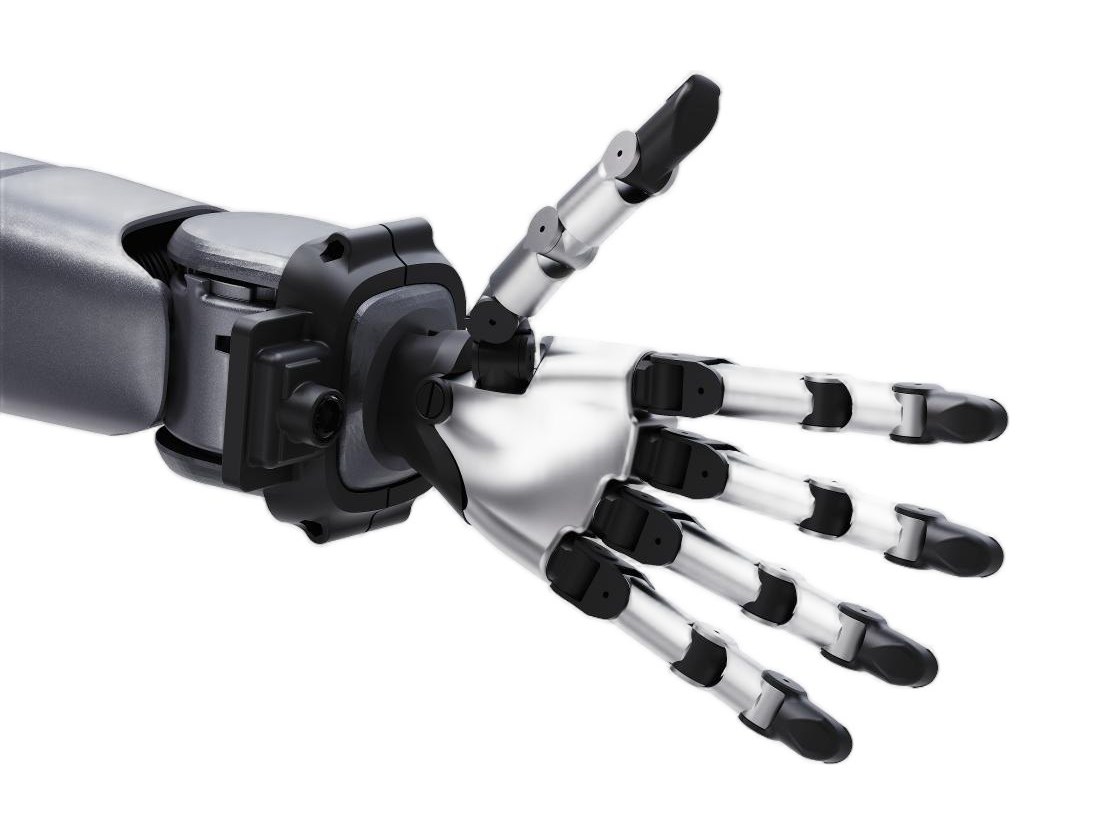
| DOF | 20 active, direct-drive, backdrivable |
| Fingers | Full opposition, with lateral sway |
| Dimensions | Approx. 185 x 80 x 40 mm (skeleton) |
| Control | 1000 Hz x 20 axes, MIT hybrid force-position |
| Interface | EtherNet (1000BASE-T) |
| Fingertip force | ≥15 N peak |
| Force sensing | 0 to 30 N, 0.005 N sensitivity |
| Power | 16 to 58 V DC |
| Wrist camera | RGB, 1920x1080, FOV D130° H120° V81° |
| Ordering | Per hand, specify left or right (usually 2 per robot) |