Specifications
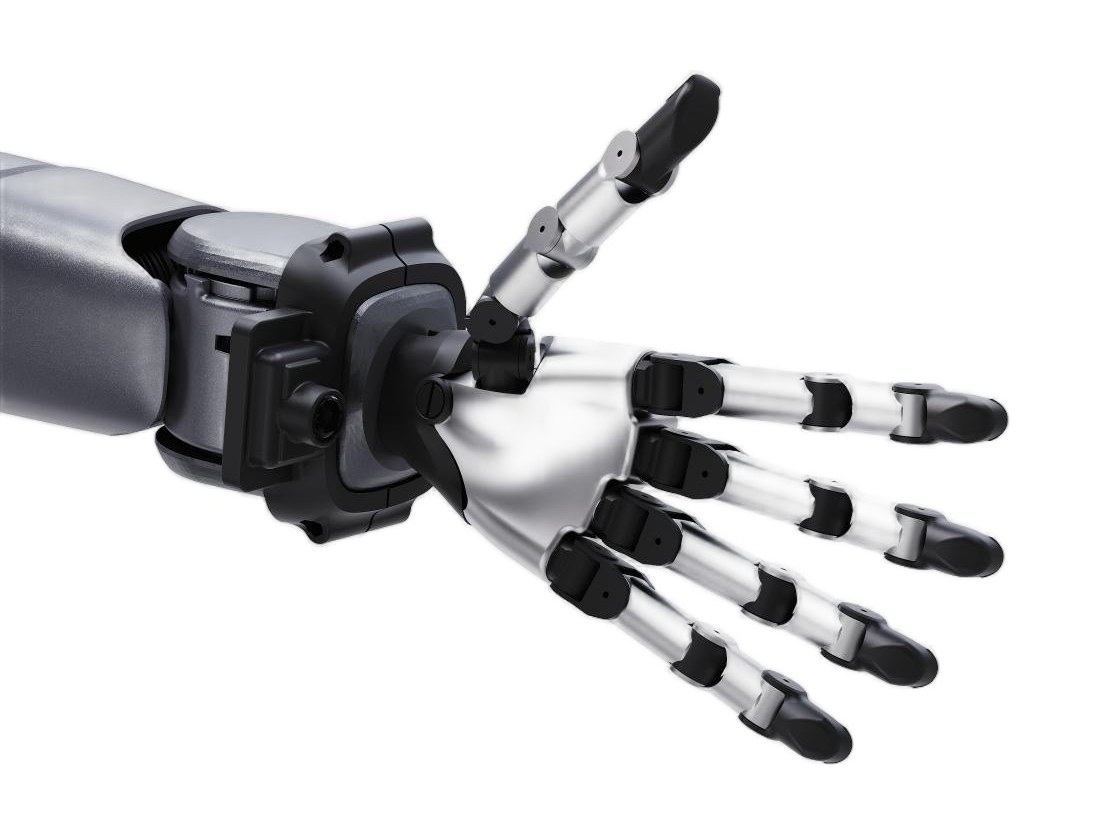
| Active DOF | 20 |
| Kinematics | Fully opposable with lateral swing, direct-drive revolute joints, back-drivable |
| Dimensions | approx. 185 x 80 x 40 mm (skeleton) |
| Control | 1000 Hz x 20 axes, MIT hybrid force/position control, EtherNet (1000BASE-T) |
| Performance | Fingertip peak force ≥ 15 N, open/close ≥ 4 times/s, joint backlash < 1° |
| Force detection | 0 to 30 N, 0.005 N sensitivity |
| Operating voltage | 16 to 58 V DC |
| Tactile sensing | None |
| Wrist camera | RGB, 1920 x 1080, FOV D 130°, H 120°, V 81° |
| In the box | 1 hand (left or right), wrist RGB camera, dedicated camera bracket, cables and accessories |